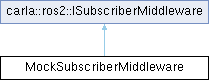
 Inheritance diagram for MockSubscriberMiddleware:
Public Member Functions | |
| std::string | GetTopicName () const override |
| bool | Init (const std::string &topic_name, void *message_ptr, bool *new_message_flag) override |
| Initialize the underlying middleware entities. | |
| bool | IsAlive () const override |
| Public Member Functions inherited from carla::ros2::ISubscriberMiddleware | |
| virtual bool | Init (const std::string &topic_name, void *message_ptr, bool *new_message_flag, const QosProfile &qos) |
| Initialize with an explicit per-topic QoS profile (see QosProfile.h). | |
| virtual | ~ISubscriberMiddleware ()=default |
Public Attributes | |
| bool | alive {true} |
| bool | init_called {false} |
| bool | init_return_value {true} |
| std::string | last_topic_name |
| bool * | stored_flag_ptr {nullptr} |
| void * | stored_message_ptr {nullptr} |
Detailed Description
Definition at line 1098 of file test_ros2_middleware.cpp.
Member Function Documentation
◆ GetTopicName()
|
inlineoverridevirtual |
- Returns
- The topic name this subscriber is bound to.
Implements carla::ros2::ISubscriberMiddleware.
Definition at line 1120 of file test_ros2_middleware.cpp.
References last_topic_name.
◆ Init()
|
inlineoverridevirtual |
Initialize the underlying middleware entities.
The middleware writes incoming messages to *message_ptr and sets *new_message_flag = true.
- Parameters
-
topic_name Full topic name. message_ptr Pointer to the message storage owned by the caller. new_message_flag Pointer to the new-message flag owned by the caller.
- Returns
- true on success.
Implements carla::ros2::ISubscriberMiddleware.
Definition at line 1108 of file test_ros2_middleware.cpp.
References init_called, init_return_value, last_topic_name, stored_flag_ptr, and stored_message_ptr.
◆ IsAlive()
|
inlineoverridevirtual |
- Returns
- true if at least one publisher is matched.
Implements carla::ros2::ISubscriberMiddleware.
Definition at line 1119 of file test_ros2_middleware.cpp.
References alive.
Member Data Documentation
◆ alive
| bool MockSubscriberMiddleware::alive {true} |
Definition at line 1101 of file test_ros2_middleware.cpp.
Referenced by IsAlive().
◆ init_called
| bool MockSubscriberMiddleware::init_called {false} |
Definition at line 1103 of file test_ros2_middleware.cpp.
Referenced by Init().
◆ init_return_value
| bool MockSubscriberMiddleware::init_return_value {true} |
Definition at line 1100 of file test_ros2_middleware.cpp.
Referenced by Init().
◆ last_topic_name
| std::string MockSubscriberMiddleware::last_topic_name |
Definition at line 1104 of file test_ros2_middleware.cpp.
Referenced by GetTopicName(), and Init().
◆ stored_flag_ptr
| bool* MockSubscriberMiddleware::stored_flag_ptr {nullptr} |
Definition at line 1106 of file test_ros2_middleware.cpp.
Referenced by Init().
◆ stored_message_ptr
| void* MockSubscriberMiddleware::stored_message_ptr {nullptr} |
Definition at line 1105 of file test_ros2_middleware.cpp.
Referenced by Init().
The documentation for this class was generated from the following file:
