#include <CarlaLidarPublisher.h>
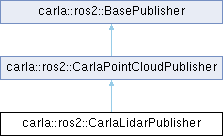
 Inheritance diagram for carla::ros2::CarlaLidarPublisher:
Public Member Functions | |
| CarlaLidarPublisher (std::string base_topic_name, std::string frame_id, bool exact_topic=false) | |
| bool | WriteExtendedPointCloud (std::int32_t seconds, std::uint32_t nanoseconds, std::uint32_t height, std::uint32_t width, const std::uint8_t *data, const std::uint32_t *channel_point_counts, std::size_t channel_count, const std::vector< float > &vertical_angles) |
| bool | WritePointCloud (std::int32_t seconds, std::uint32_t nanoseconds, std::uint32_t height, std::uint32_t width, const std::uint8_t *data) |
| Public Member Functions inherited from carla::ros2::CarlaPointCloudPublisher | |
| CarlaPointCloudPublisher (CarlaPointCloudPublisher &&) noexcept=default | |
| CarlaPointCloudPublisher (const CarlaPointCloudPublisher &)=delete | |
| CarlaPointCloudPublisher (std::string base_topic_name, std::string frame_id, bool exact_topic=false) | |
| CarlaPointCloudPublisher & | operator= (CarlaPointCloudPublisher &&) noexcept=default |
| CarlaPointCloudPublisher & | operator= (const CarlaPointCloudPublisher &)=delete |
| bool | Publish () override |
| bool | WritePointCloud (std::int32_t seconds, std::uint32_t nanoseconds, std::uint32_t height, std::uint32_t width, const std::uint8_t *data) |
| ~CarlaPointCloudPublisher () override | |
| Public Member Functions inherited from carla::ros2::BasePublisher | |
| BasePublisher ()=default | |
| BasePublisher (BasePublisher &&)=delete | |
| BasePublisher (const BasePublisher &)=delete | |
| BasePublisher (std::string base_topic_name) | |
| BasePublisher (std::string base_topic_name, std::string frame_id) | |
| BasePublisher (void *actor, std::string base_topic_name, std::string frame_id) | |
| void * | GetActor () const noexcept |
| const std::string & | GetBaseTopicName () const noexcept |
| const std::string & | GetFrameId () const noexcept |
| BasePublisher & | operator= (BasePublisher &&)=delete |
| BasePublisher & | operator= (const BasePublisher &)=delete |
| virtual | ~BasePublisher ()=default |
Private Member Functions | |
| std::vector< std::uint8_t > | ComputePointCloud (std::uint32_t height, std::uint32_t width, const std::uint8_t *data) const override |
| std::size_t | GetFieldDescriptorCount () const override |
| const PointFieldDescriptor * | GetFieldDescriptors () const override |
| std::size_t | GetPointSize () const override |
Private Attributes | |
| std::vector< std::uint32_t > | _channel_point_counts |
| bool | _extended = false |
| std::vector< float > | _vertical_angles |
Additional Inherited Members | |
| Protected Attributes inherited from carla::ros2::BasePublisher | |
| void * | _actor {nullptr} |
| std::string | _base_topic_name |
| std::string | _frame_id |
Detailed Description
Definition at line 17 of file CarlaLidarPublisher.h.
Constructor & Destructor Documentation
◆ CarlaLidarPublisher()
|
inline |
Definition at line 19 of file CarlaLidarPublisher.h.
Member Function Documentation
◆ ComputePointCloud()
|
overrideprivatevirtual |
Implements carla::ros2::CarlaPointCloudPublisher.
Definition at line 87 of file CarlaLidarPublisher.cpp.
References _channel_point_counts, _extended, _vertical_angles, channel, elevation, and point.
◆ GetFieldDescriptorCount()
|
overrideprivatevirtual |
Implements carla::ros2::CarlaPointCloudPublisher.
Definition at line 66 of file CarlaLidarPublisher.cpp.
References _extended, carla::ros2::kLidarFields, and carla::ros2::kLidarFieldsEx.
◆ GetFieldDescriptors()
|
overrideprivatevirtual |
Implements carla::ros2::CarlaPointCloudPublisher.
Definition at line 62 of file CarlaLidarPublisher.cpp.
References _extended, carla::ros2::kLidarFields, and carla::ros2::kLidarFieldsEx.
◆ GetPointSize()
|
overrideprivatevirtual |
Implements carla::ros2::CarlaPointCloudPublisher.
Definition at line 58 of file CarlaLidarPublisher.cpp.
References _extended.
◆ WriteExtendedPointCloud()
| bool carla::ros2::CarlaLidarPublisher::WriteExtendedPointCloud | ( | std::int32_t | seconds, |
| std::uint32_t | nanoseconds, | ||
| std::uint32_t | height, | ||
| std::uint32_t | width, | ||
| const std::uint8_t * | data, | ||
| const std::uint32_t * | channel_point_counts, | ||
| std::size_t | channel_count, | ||
| const std::vector< float > & | vertical_angles | ||
| ) |
Definition at line 70 of file CarlaLidarPublisher.cpp.
References _channel_point_counts, _extended, _vertical_angles, and carla::ros2::CarlaPointCloudPublisher::WritePointCloud().
◆ WritePointCloud()
|
inline |
Definition at line 25 of file CarlaLidarPublisher.h.
References _extended, and carla::ros2::CarlaPointCloudPublisher::WritePointCloud().
Member Data Documentation
◆ _channel_point_counts
|
private |
Definition at line 62 of file CarlaLidarPublisher.h.
Referenced by ComputePointCloud(), and WriteExtendedPointCloud().
◆ _extended
|
private |
Definition at line 61 of file CarlaLidarPublisher.h.
Referenced by ComputePointCloud(), GetFieldDescriptorCount(), GetFieldDescriptors(), GetPointSize(), WriteExtendedPointCloud(), and WritePointCloud().
◆ _vertical_angles
|
private |
Definition at line 63 of file CarlaLidarPublisher.h.
Referenced by ComputePointCloud(), and WriteExtendedPointCloud().
The documentation for this class was generated from the following files:
