#include <ConstantVelocityAgent.h>
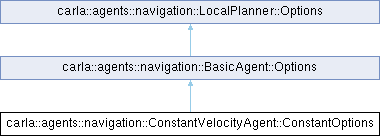
 Inheritance diagram for carla::agents::navigation::ConstantVelocityAgent::ConstantOptions:
Public Attributes | |
| float | restart_time = std::numeric_limits<float>::infinity() |
| bool | use_basic_behavior = false |
| Public Attributes inherited from carla::agents::navigation::BasicAgent::Options | |
| float | base_tlight_threshold = 5.0f |
| float | base_vehicle_threshold = 5.0f |
| float | detection_speed_ratio = 1.0f |
| bool | ignore_stop_signs = false |
| bool | ignore_traffic_lights = false |
| bool | ignore_vehicles = false |
| float | max_brake = 0.6f |
| float | sampling_resolution = 2.0f |
| bool | use_bbs_detection = false |
| Public Attributes inherited from carla::agents::navigation::LocalPlanner::Options | |
| float | base_min_distance = 3.0f |
| float | distance_ratio = 0.5f |
| float | dt = 1.0f / 20.0f |
| bool | follow_speed_limits = false |
| VehiclePIDController::LateralArgs | lateral {} |
| VehiclePIDController::LongitudinalArgs | longitudinal {} |
| float | max_brake = 0.30f |
| float | max_steering = 0.80f |
| float | max_throttle = 0.75f |
| float | offset = 0.0f |
| float | sampling_radius = 2.0f |
| float | target_speed = 20.0f |
Detailed Description
Definition at line 35 of file ConstantVelocityAgent.h.
Member Data Documentation
◆ restart_time
| float carla::agents::navigation::ConstantVelocityAgent::ConstantOptions::restart_time = std::numeric_limits<float>::infinity() |
Definition at line 37 of file ConstantVelocityAgent.h.
◆ use_basic_behavior
| bool carla::agents::navigation::ConstantVelocityAgent::ConstantOptions::use_basic_behavior = false |
Definition at line 36 of file ConstantVelocityAgent.h.
The documentation for this struct was generated from the following file:
