#include <Junction.h>
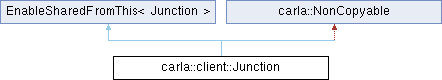
 Inheritance diagram for carla::client::Junction:
Public Member Functions | |
| std::vector< SharedPtr< Road > > | GetAdjacentRoads () const |
| The roads outside the junction that meet it. | |
| geom::BoundingBox | GetBoundingBox () const |
| std::vector< SharedPtr< Road > > | GetConnectingRoads () const |
| The roads inside the junction, carrying traffic through it. | |
| std::vector< SharedPtr< Lane > > | GetEntryLanes (road::Lane::LaneType type=road::Lane::LaneType::Driving) const |
| Lanes on the adjacent roads that feed into the junction. | |
| std::vector< SharedPtr< Waypoint > > | GetEntryWaypoints (road::Lane::LaneType type=road::Lane::LaneType::Driving) const |
| One waypoint per entry lane, on the adjacent road where it meets the junction. | |
| std::vector< SharedPtr< Lane > > | GetExitLanes (road::Lane::LaneType type=road::Lane::LaneType::Driving) const |
| Lanes on the adjacent roads that the junction feeds into. | |
| std::vector< SharedPtr< Waypoint > > | GetExitWaypoints (road::Lane::LaneType type=road::Lane::LaneType::Driving) const |
| One waypoint per exit lane, on the adjacent road where it leaves the junction. | |
| carla::road::JuncId | GetId () const |
| std::vector< std::pair< SharedPtr< Waypoint >, SharedPtr< Waypoint > > > | GetWaypoints (road::Lane::LaneType type=road::Lane::LaneType::Driving) const |
Private Member Functions | |
| std::vector< SharedPtr< Lane > > | GetNeighbourLanes (road::Lane::LaneType type, bool entering) const |
| Shared implementation of GetEntryLanes / GetExitLanes. | |
| std::vector< SharedPtr< Waypoint > > | GetNeighbourWaypoints (road::Lane::LaneType type, bool entering) const |
| Shared implementation of GetEntryWaypoints / GetExitWaypoints. | |
| Junction (SharedPtr< const Map > parent, const road::Junction *junction) | |
| Private Member Functions inherited from carla::NonCopyable | |
| NonCopyable ()=default | |
| NonCopyable (const NonCopyable &)=delete | |
| NonCopyable (NonCopyable &&)=delete | |
| NonCopyable & | operator= (const NonCopyable &)=delete |
| NonCopyable & | operator= (NonCopyable &&)=delete |
Private Attributes | |
| geom::BoundingBox | _bounding_box |
| road::JuncId | _id |
| SharedPtr< const Map > | _parent |
Friends | |
| class | Map |
Detailed Description
Definition at line 25 of file client/Junction.h.
Constructor & Destructor Documentation
◆ Junction()
|
private |
Definition at line 19 of file Junction.cpp.
References _bounding_box, _id, and junction.
Member Function Documentation
◆ GetAdjacentRoads()
The roads outside the junction that meet it.
OpenDRIVE calls these "incoming", but a road has no inherent direction – the same road is an exit for traffic going the other way – so they are adjacent here.
Definition at line 53 of file Junction.cpp.
◆ GetBoundingBox()
| geom::BoundingBox carla::client::Junction::GetBoundingBox | ( | ) | const |
Definition at line 29 of file Junction.cpp.
References _bounding_box.
◆ GetConnectingRoads()
◆ GetEntryLanes()
| std::vector< SharedPtr< Lane > > carla::client::Junction::GetEntryLanes | ( | road::Lane::LaneType | type = road::Lane::LaneType::Driving | ) | const |
Lanes on the adjacent roads that feed into the junction.
Definition at line 111 of file Junction.cpp.
References GetNeighbourLanes().
◆ GetEntryWaypoints()
| std::vector< SharedPtr< Waypoint > > carla::client::Junction::GetEntryWaypoints | ( | road::Lane::LaneType | type = road::Lane::LaneType::Driving | ) | const |
One waypoint per entry lane, on the adjacent road where it meets the junction.
Outside the junction, like GetEntryLanes(); for the waypoints on the connecting roads inside it, use GetWaypoints().
Definition at line 150 of file Junction.cpp.
References GetNeighbourWaypoints().
◆ GetExitLanes()
| std::vector< SharedPtr< Lane > > carla::client::Junction::GetExitLanes | ( | road::Lane::LaneType | type = road::Lane::LaneType::Driving | ) | const |
Lanes on the adjacent roads that the junction feeds into.
Definition at line 115 of file Junction.cpp.
References GetNeighbourLanes().
◆ GetExitWaypoints()
| std::vector< SharedPtr< Waypoint > > carla::client::Junction::GetExitWaypoints | ( | road::Lane::LaneType | type = road::Lane::LaneType::Driving | ) | const |
One waypoint per exit lane, on the adjacent road where it leaves the junction.
Definition at line 154 of file Junction.cpp.
References GetNeighbourWaypoints().
◆ GetId()
|
inline |
◆ GetNeighbourLanes()
|
private |
Shared implementation of GetEntryLanes / GetExitLanes.
Definition at line 78 of file Junction.cpp.
References _id, GetWaypoints(), and road.
Referenced by GetEntryLanes(), GetExitLanes(), and GetNeighbourWaypoints().
◆ GetNeighbourWaypoints()
|
private |
Shared implementation of GetEntryWaypoints / GetExitWaypoints.
Definition at line 137 of file Junction.cpp.
References GetNeighbourLanes(), and carla::client::JunctionSideDistance().
Referenced by GetEntryWaypoints(), and GetExitWaypoints().
◆ GetWaypoints()
| std::vector< std::pair< SharedPtr< Waypoint >, SharedPtr< Waypoint > > > carla::client::Junction::GetWaypoints | ( | road::Lane::LaneType | type = road::Lane::LaneType::Driving | ) | const |
Definition at line 24 of file Junction.cpp.
References _parent, and GetId().
Referenced by GetNeighbourLanes().
Friends And Related Symbol Documentation
◆ Map
|
friend |
Definition at line 71 of file client/Junction.h.
Member Data Documentation
◆ _bounding_box
|
private |
Definition at line 87 of file client/Junction.h.
Referenced by GetBoundingBox(), and Junction().
◆ _id
|
private |
Definition at line 89 of file client/Junction.h.
Referenced by GetAdjacentRoads(), GetConnectingRoads(), GetId(), GetNeighbourLanes(), and Junction().
◆ _parent
Definition at line 85 of file client/Junction.h.
Referenced by GetAdjacentRoads(), GetConnectingRoads(), and GetWaypoints().
The documentation for this class was generated from the following files:
