#include <Waypoint.h>
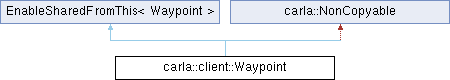
 Inheritance diagram for carla::client::Waypoint:
Public Member Functions | |
| std::vector< SharedPtr< Landmark > > | GetAllLandmarksInDistance (double distance, bool stop_at_junction=false) const |
| Returns a list of landmarks from the current position to a certain distance. | |
| auto | GetDistance () const |
| uint64_t | GetId () const |
| Returns an unique Id identifying this waypoint. | |
| SharedPtr< Junction > | GetJunction () const |
| road::JuncId | GetJunctionId () const |
| std::vector< SharedPtr< Landmark > > | GetLandmarksOfTypeInDistance (double distance, std::string filter_type, bool stop_at_junction=false) const |
| Returns a list of landmarks from the current position to a certain distance Filters by specified type. | |
| SharedPtr< Lane > | GetLane () const |
| The lane this waypoint samples. | |
| road::element::LaneMarking::LaneChange | GetLaneChange () const |
| auto | GetLaneId () const |
| double | GetLaneWidth () const |
| SharedPtr< Waypoint > | GetLeft () const |
| std::optional< road::element::LaneMarking > | GetLeftLaneMarking () const |
| std::vector< SharedPtr< Waypoint > > | GetNext (double distance) const |
| std::vector< SharedPtr< Waypoint > > | GetNextUntilLaneEnd (double distance) const |
| Returns a list of waypoints separated by distance from the current waypoint to the end of the lane. | |
| std::vector< SharedPtr< Waypoint > > | GetPrevious (double distance) const |
| std::vector< SharedPtr< Waypoint > > | GetPreviousUntilLaneStart (double distance) const |
| Returns a list of waypoints separated by distance from the current waypoint to the start of the lane. | |
| SharedPtr< Waypoint > | GetRight () const |
| std::optional< road::element::LaneMarking > | GetRightLaneMarking () const |
| SharedPtr< Road > | GetRoad () const |
| The road this waypoint samples. | |
| auto | GetRoadId () const |
| auto | GetSectionId () const |
| const geom::Transform & | GetTransform () const |
| road::Lane::LaneType | GetType () const |
| bool | IsJunction () const |
| bool | IsPositiveDirection () const |
| bool | IsRHT () const |
| ~Waypoint () | |
Private Member Functions | |
| Waypoint (SharedPtr< const Map > parent, road::element::Waypoint waypoint) | |
| Private Member Functions inherited from carla::NonCopyable | |
| NonCopyable ()=default | |
| NonCopyable (const NonCopyable &)=delete | |
| NonCopyable (NonCopyable &&)=delete | |
| NonCopyable & | operator= (const NonCopyable &)=delete |
| NonCopyable & | operator= (NonCopyable &&)=delete |
Private Attributes | |
| std::pair< const road::element::RoadInfoMarkRecord *, const road::element::RoadInfoMarkRecord * > | _mark_record |
| SharedPtr< const Map > | _parent |
| geom::Transform | _transform |
| road::element::Waypoint | _waypoint |
Friends | |
| class | Map |
Detailed Description
Definition at line 29 of file client/Waypoint.h.
Constructor & Destructor Documentation
◆ ~Waypoint()
|
default |
◆ Waypoint()
|
private |
Definition at line 20 of file client/Waypoint.cpp.
Member Function Documentation
◆ GetAllLandmarksInDistance()
| std::vector< SharedPtr< Landmark > > carla::client::Waypoint::GetAllLandmarksInDistance | ( | double | distance, |
| bool | stop_at_junction = false |
||
| ) | const |
Returns a list of landmarks from the current position to a certain distance.
Definition at line 234 of file client/Waypoint.cpp.
References _parent, _waypoint, and distance.
Referenced by carla::client::World::GetTrafficLightsFromWaypoint().
◆ GetDistance()
|
inline |
Definition at line 56 of file client/Waypoint.h.
References _waypoint, and carla::road::element::Waypoint::s.
Referenced by GetNextUntilLaneEnd(), and GetPreviousUntilLaneStart().
◆ GetId()
|
inline |
Returns an unique Id identifying this waypoint.
The Id takes into account OpenDrive's road Id, lane Id, and s distance on its road segment up to half-centimetre precision.
Definition at line 40 of file client/Waypoint.h.
References _waypoint.
◆ GetJunction()
Definition at line 36 of file client/Waypoint.cpp.
References _parent, and IsJunction().
◆ GetJunctionId()
| road::JuncId carla::client::Waypoint::GetJunctionId | ( | ) | const |
Definition at line 28 of file client/Waypoint.cpp.
References _parent, _waypoint, and carla::road::element::Waypoint::road_id.
Referenced by carla::client::Map::GetJunction().
◆ GetLandmarksOfTypeInDistance()
| std::vector< SharedPtr< Landmark > > carla::client::Waypoint::GetLandmarksOfTypeInDistance | ( | double | distance, |
| std::string | filter_type, | ||
| bool | stop_at_junction = false |
||
| ) | const |
Returns a list of landmarks from the current position to a certain distance Filters by specified type.
Definition at line 252 of file client/Waypoint.cpp.
◆ GetLane()
The lane this waypoint samples.
Definition at line 43 of file client/Waypoint.cpp.
References _parent, _waypoint, carla::road::element::Waypoint::lane_id, carla::road::element::Waypoint::road_id, and carla::road::element::Waypoint::section_id.
◆ GetLaneChange()
| road::element::LaneMarking::LaneChange carla::client::Waypoint::GetLaneChange | ( | ) | const |
Definition at line 190 of file client/Waypoint.cpp.
References _mark_record, _parent, _waypoint, IsPositiveDirection(), carla::road::element::Waypoint::lane_id, and road.
◆ GetLaneId()
|
inline |
Definition at line 52 of file client/Waypoint.h.
References _waypoint, and carla::road::element::Waypoint::lane_id.
◆ GetLaneWidth()
| double carla::client::Waypoint::GetLaneWidth | ( | ) | const |
Definition at line 51 of file client/Waypoint.cpp.
◆ GetLeft()
Definition at line 149 of file client/Waypoint.cpp.
◆ GetLeftLaneMarking()
| std::optional< road::element::LaneMarking > carla::client::Waypoint::GetLeftLaneMarking | ( | ) | const |
Definition at line 167 of file client/Waypoint.cpp.
References _mark_record, _parent, _waypoint, and road.
◆ GetNext()
Definition at line 60 of file client/Waypoint.cpp.
References _parent, _waypoint, and distance.
Referenced by GetNextUntilLaneEnd().
◆ GetNextUntilLaneEnd()
| std::vector< SharedPtr< Waypoint > > carla::client::Waypoint::GetNextUntilLaneEnd | ( | double | distance | ) | const |
Returns a list of waypoints separated by distance from the current waypoint to the end of the lane.
Definition at line 80 of file client/Waypoint.cpp.
References _parent, _waypoint, distance, GetDistance(), GetNext(), GetRoadId(), and IsPositiveDirection().
◆ GetPrevious()
Definition at line 70 of file client/Waypoint.cpp.
References _parent, _waypoint, and distance.
Referenced by GetPreviousUntilLaneStart().
◆ GetPreviousUntilLaneStart()
| std::vector< SharedPtr< Waypoint > > carla::client::Waypoint::GetPreviousUntilLaneStart | ( | double | distance | ) | const |
Returns a list of waypoints separated by distance from the current waypoint to the start of the lane.
Definition at line 109 of file client/Waypoint.cpp.
References _parent, _waypoint, distance, GetDistance(), GetPrevious(), GetRoadId(), and IsPositiveDirection().
◆ GetRight()
Definition at line 140 of file client/Waypoint.cpp.
◆ GetRightLaneMarking()
| std::optional< road::element::LaneMarking > carla::client::Waypoint::GetRightLaneMarking | ( | ) | const |
Definition at line 158 of file client/Waypoint.cpp.
References _mark_record, _parent, _waypoint, and road.
◆ GetRoad()
The road this waypoint samples.
Definition at line 47 of file client/Waypoint.cpp.
References _parent, _waypoint, and carla::road::element::Waypoint::road_id.
◆ GetRoadId()
|
inline |
Definition at line 44 of file client/Waypoint.h.
References _waypoint, and carla::road::element::Waypoint::road_id.
Referenced by GetNextUntilLaneEnd(), and GetPreviousUntilLaneStart().
◆ GetSectionId()
|
inline |
Definition at line 48 of file client/Waypoint.h.
References _waypoint, and carla::road::element::Waypoint::section_id.
◆ GetTransform()
|
inline |
Definition at line 60 of file client/Waypoint.h.
References _transform.
◆ GetType()
| road::Lane::LaneType carla::client::Waypoint::GetType | ( | ) | const |
Definition at line 56 of file client/Waypoint.cpp.
◆ IsJunction()
| bool carla::client::Waypoint::IsJunction | ( | ) | const |
Definition at line 32 of file client/Waypoint.cpp.
References _parent, _waypoint, and carla::road::element::Waypoint::road_id.
Referenced by GetJunction().
◆ IsPositiveDirection()
| bool carla::client::Waypoint::IsPositiveDirection | ( | ) | const |
Definition at line 271 of file client/Waypoint.cpp.
References _parent, and _waypoint.
Referenced by GetLaneChange(), GetNextUntilLaneEnd(), and GetPreviousUntilLaneStart().
◆ IsRHT()
| bool carla::client::Waypoint::IsRHT | ( | ) | const |
Definition at line 275 of file client/Waypoint.cpp.
Friends And Related Symbol Documentation
◆ Map
|
friend |
Definition at line 117 of file client/Waypoint.h.
Member Data Documentation
◆ _mark_record
|
private |
Definition at line 130 of file client/Waypoint.h.
Referenced by GetLaneChange(), GetLeftLaneMarking(), and GetRightLaneMarking().
◆ _parent
Definition at line 121 of file client/Waypoint.h.
Referenced by GetAllLandmarksInDistance(), GetJunction(), GetJunctionId(), GetLandmarksOfTypeInDistance(), GetLane(), GetLaneChange(), GetLaneWidth(), GetLeft(), GetLeftLaneMarking(), GetNext(), GetNextUntilLaneEnd(), GetPrevious(), GetPreviousUntilLaneStart(), GetRight(), GetRightLaneMarking(), GetRoad(), GetType(), IsJunction(), IsPositiveDirection(), and IsRHT().
◆ _transform
|
private |
Definition at line 125 of file client/Waypoint.h.
Referenced by GetTransform().
◆ _waypoint
|
private |
Definition at line 123 of file client/Waypoint.h.
Referenced by GetAllLandmarksInDistance(), GetDistance(), GetId(), GetJunctionId(), GetLandmarksOfTypeInDistance(), GetLane(), GetLaneChange(), GetLaneId(), GetLaneWidth(), GetLeft(), GetLeftLaneMarking(), GetNext(), GetNextUntilLaneEnd(), GetPrevious(), GetPreviousUntilLaneStart(), GetRight(), GetRightLaneMarking(), GetRoad(), GetRoadId(), GetSectionId(), GetType(), IsJunction(), IsPositiveDirection(), and IsRHT().
The documentation for this class was generated from the following files:
