A sensor to register collisions. More...
#include <ObstacleDetectionSensor.h>
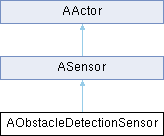
 Inheritance diagram for AObstacleDetectionSensor:
Public Member Functions | |
| AObstacleDetectionSensor (const FObjectInitializer &ObjectInitializer) | |
| virtual void | PostPhysTick (UWorld *World, ELevelTick TickType, float DeltaSeconds) override |
| void | Set (const FActorDescription &Description) override |
| Public Member Functions inherited from ASensor | |
| bool | AreClientsListening () |
| ASensor (const FObjectInitializer &ObjectInitializer) | |
| virtual void | BeginPlay () |
| void | ClearReadyToTick () |
| std::optional< FActorAttribute > | GetAttribute (const FString Name) |
| const UCarlaEpisode & | GetEpisode () const |
| virtual void | GetMirrorState (carla::multigpu::SensorState &State) const |
| Multi-GPU: the runtime state this sensor starts its next tick from (noise generator, sweep angle, history). | |
| URandomEngine * | GetRandomEngine () |
| float | GetReadyToTickDeltaSeconds () const |
| int32 | GetSeed () const |
| auto | GetToken () const |
| Return the token that allows subscribing to this sensor's stream. | |
| bool | IsReadyToTick () const |
| bool | IsStreamReady () |
| FDataStream | MoveDataStream () |
| virtual void | OnFirstClientConnected () |
| virtual void | OnLastClientDisconnected () |
| void | PostPhysTickInternal (UWorld *World, ELevelTick TickType, float DeltaSeconds) |
| virtual void | PrePhysTick (float DeltaSeconds) |
| void | SetDataStream (FDataStream InStream) |
| Replace the FDataStream associated with this sensor. | |
| void | SetEpisode (const UCarlaEpisode &InEpisode) |
| virtual void | SetMirrorState (const carla::multigpu::SensorState &State) |
| void | SetPrimaryTick (float DeltaSeconds) |
| Multi-GPU secondary: tick in this engine frame, with the primary's delta. | |
| void | SetSavingDataToDisk (bool bSavingData) |
| void | SetSeed (int32 InSeed) |
| void | Tick (const float DeltaTime) final |
Static Public Member Functions | |
| static FActorDefinition | GetSensorDefinition () |
| Static Public Member Functions inherited from ASensor | |
| static FSensorCaptureContext | MakeCaptureContext (const ASensor &Sensor) |
| Call on the game thread right after CaptureScene(). | |
Private Member Functions | |
| void | OnObstacleDetectionEvent (AActor *Actor, AActor *OtherActor, float Distance, const FHitResult &Hit) |
Private Attributes | |
| bool | bDebugLineTrace = false |
| bool | bOnlyDynamics = false |
| float | Distance |
| float | HitRadius |
Additional Inherited Members | |
| Protected Member Functions inherited from ASensor | |
| void | EndPlay (EEndPlayReason::Type EndPlayReason) override |
| template<typename SensorType > | |
| FAsyncDataStream | GetDataStream (SensorType &&Self) |
| Return the FDataStream associated with this sensor. | |
| void | PostActorCreated () override |
| Static Protected Member Functions inherited from ASensor | |
| template<typename SensorType , typename ElementType > | |
| static void | SendDataToClient (SensorType &&Sensor, TArrayView< ElementType > SensorData, const FSensorCaptureContext &CaptureContext) |
| Protected Attributes inherited from ASensor | |
| bool | bIsActive = false |
| bool | bSavingDataToDisk = false |
| URandomEngine * | RandomEngine = nullptr |
| Random Engine used to provide noise for sensor output. | |
| int32 | Seed = 123456789 |
| Seed of the pseudo-random engine. | |
Detailed Description
A sensor to register collisions.
Definition at line 18 of file ObstacleDetectionSensor.h.
Constructor & Destructor Documentation
◆ AObstacleDetectionSensor()
| AObstacleDetectionSensor::AObstacleDetectionSensor | ( | const FObjectInitializer & | ObjectInitializer | ) |
Definition at line 19 of file ObstacleDetectionSensor.cpp.
Member Function Documentation
◆ GetSensorDefinition()
|
static |
Definition at line 25 of file ObstacleDetectionSensor.cpp.
References UActorBlueprintFunctionLibrary::MakeObstacleDetectorDefinitions().
◆ OnObstacleDetectionEvent()
|
private |
Definition at line 132 of file ObstacleDetectionSensor.cpp.
References carla::streaming::detail::token_type::get_stream_id(), ASensor::GetDataStream(), ASensor::GetEpisode(), carla::ros2::ROS2::GetInstance(), ASensor::GetToken(), and ASensor::IsStreamReady().
Referenced by PostPhysTick().
◆ PostPhysTick()
|
overridevirtual |
Reimplemented from ASensor.
Definition at line 56 of file ObstacleDetectionSensor.cpp.
References bDebugLineTrace, bOnlyDynamics, Distance, HitRadius, OnObstacleDetectionEvent(), and PostPhysTick().
Referenced by PostPhysTick().
◆ Set()
|
overridevirtual |
Reimplemented from ASensor.
Definition at line 32 of file ObstacleDetectionSensor.cpp.
References bDebugLineTrace, bOnlyDynamics, Distance, HitRadius, UActorBlueprintFunctionLibrary::RetrieveActorAttributeToBool(), UActorBlueprintFunctionLibrary::RetrieveActorAttributeToFloat(), and FActorDescription::Variations.
Member Data Documentation
◆ bDebugLineTrace
|
private |
Definition at line 49 of file ObstacleDetectionSensor.h.
Referenced by PostPhysTick(), and Set().
◆ bOnlyDynamics
|
private |
Definition at line 47 of file ObstacleDetectionSensor.h.
Referenced by PostPhysTick(), and Set().
◆ Distance
|
private |
Definition at line 43 of file ObstacleDetectionSensor.h.
Referenced by PostPhysTick(), and Set().
◆ HitRadius
|
private |
Definition at line 45 of file ObstacleDetectionSensor.h.
Referenced by PostPhysTick(), and Set().
The documentation for this class was generated from the following files:
