#include <CarlaPointCloudPublisher.h>
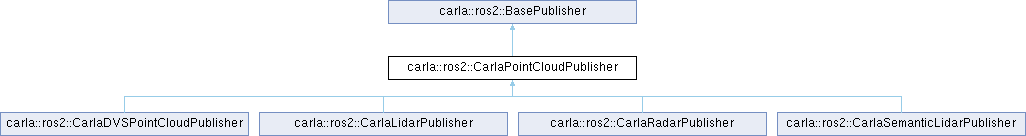
 Inheritance diagram for carla::ros2::CarlaPointCloudPublisher:
Public Member Functions | |
| CarlaPointCloudPublisher (CarlaPointCloudPublisher &&) noexcept=default | |
| CarlaPointCloudPublisher (const CarlaPointCloudPublisher &)=delete | |
| CarlaPointCloudPublisher (std::string base_topic_name, std::string frame_id, bool exact_topic=false) | |
| CarlaPointCloudPublisher & | operator= (CarlaPointCloudPublisher &&) noexcept=default |
| CarlaPointCloudPublisher & | operator= (const CarlaPointCloudPublisher &)=delete |
| bool | Publish () override |
| bool | WritePointCloud (std::int32_t seconds, std::uint32_t nanoseconds, std::uint32_t height, std::uint32_t width, const std::uint8_t *data) |
| ~CarlaPointCloudPublisher () override | |
| Public Member Functions inherited from carla::ros2::BasePublisher | |
| BasePublisher ()=default | |
| BasePublisher (BasePublisher &&)=delete | |
| BasePublisher (const BasePublisher &)=delete | |
| BasePublisher (std::string base_topic_name) | |
| BasePublisher (std::string base_topic_name, std::string frame_id) | |
| BasePublisher (void *actor, std::string base_topic_name, std::string frame_id) | |
| void * | GetActor () const noexcept |
| const std::string & | GetBaseTopicName () const noexcept |
| const std::string & | GetFrameId () const noexcept |
| BasePublisher & | operator= (BasePublisher &&)=delete |
| BasePublisher & | operator= (const BasePublisher &)=delete |
| virtual | ~BasePublisher ()=default |
Protected Member Functions | |
| virtual std::vector< std::uint8_t > | ComputePointCloud (std::uint32_t height, std::uint32_t width, const std::uint8_t *data) const =0 |
| virtual std::size_t | GetFieldDescriptorCount () const =0 |
| virtual const PointFieldDescriptor * | GetFieldDescriptors () const =0 |
| virtual std::size_t | GetPointSize () const =0 |
Private Member Functions | |
| bool | WritePointCloud (std::int32_t seconds, std::uint32_t nanoseconds, std::uint32_t height, std::uint32_t width, std::vector< std::uint8_t > data) |
Private Attributes | |
| std::shared_ptr< PublisherImpl< CarlaPointCloudMsgTraits > > | _impl |
Additional Inherited Members | |
| Protected Attributes inherited from carla::ros2::BasePublisher | |
| void * | _actor {nullptr} |
| std::string | _base_topic_name |
| std::string | _frame_id |
Detailed Description
Definition at line 37 of file CarlaPointCloudPublisher.h.
Constructor & Destructor Documentation
◆ CarlaPointCloudPublisher() [1/3]
| carla::ros2::CarlaPointCloudPublisher::CarlaPointCloudPublisher | ( | std::string | base_topic_name, |
| std::string | frame_id, | ||
| bool | exact_topic = false |
||
| ) |
Definition at line 62 of file CarlaPointCloudPublisher.cpp.
References _impl, carla::ros2::BasePublisher::GetBaseTopicName(), and carla::log_error().
◆ ~CarlaPointCloudPublisher()
|
overridedefault |
◆ CarlaPointCloudPublisher() [2/3]
|
delete |
◆ CarlaPointCloudPublisher() [3/3]
|
defaultnoexcept |
Member Function Documentation
◆ ComputePointCloud()
|
protectedpure virtual |
Implemented in carla::ros2::CarlaDVSPointCloudPublisher, carla::ros2::CarlaLidarPublisher, carla::ros2::CarlaRadarPublisher, and carla::ros2::CarlaSemanticLidarPublisher.
Referenced by WritePointCloud().
◆ GetFieldDescriptorCount()
|
protectedpure virtual |
Implemented in carla::ros2::CarlaDVSPointCloudPublisher, carla::ros2::CarlaLidarPublisher, carla::ros2::CarlaRadarPublisher, and carla::ros2::CarlaSemanticLidarPublisher.
Referenced by WritePointCloud().
◆ GetFieldDescriptors()
|
protectedpure virtual |
Implemented in carla::ros2::CarlaDVSPointCloudPublisher, carla::ros2::CarlaLidarPublisher, carla::ros2::CarlaRadarPublisher, and carla::ros2::CarlaSemanticLidarPublisher.
Referenced by WritePointCloud().
◆ GetPointSize()
|
protectedpure virtual |
Implemented in carla::ros2::CarlaDVSPointCloudPublisher, carla::ros2::CarlaLidarPublisher, carla::ros2::CarlaRadarPublisher, and carla::ros2::CarlaSemanticLidarPublisher.
Referenced by WritePointCloud().
◆ operator=() [1/2]
|
defaultnoexcept |
◆ operator=() [2/2]
|
delete |
◆ Publish()
|
overridevirtual |
Implements carla::ros2::BasePublisher.
Definition at line 73 of file CarlaPointCloudPublisher.cpp.
References _impl.
◆ WritePointCloud() [1/2]
| bool carla::ros2::CarlaPointCloudPublisher::WritePointCloud | ( | std::int32_t | seconds, |
| std::uint32_t | nanoseconds, | ||
| std::uint32_t | height, | ||
| std::uint32_t | width, | ||
| const std::uint8_t * | data | ||
| ) |
Definition at line 77 of file CarlaPointCloudPublisher.cpp.
References ComputePointCloud(), and WritePointCloud().
Referenced by carla::ros2::CarlaLidarPublisher::WriteExtendedPointCloud(), carla::ros2::CarlaLidarPublisher::WritePointCloud(), and WritePointCloud().
◆ WritePointCloud() [2/2]
|
private |
Definition at line 88 of file CarlaPointCloudPublisher.cpp.
References _impl, GetFieldDescriptorCount(), GetFieldDescriptors(), carla::ros2::BasePublisher::GetFrameId(), and GetPointSize().
Member Data Documentation
◆ _impl
|
private |
Definition at line 78 of file CarlaPointCloudPublisher.h.
Referenced by CarlaPointCloudPublisher(), Publish(), and WritePointCloud().
The documentation for this class was generated from the following files:
