Autoware GNSS sensor ("sensor.other.autoware_gnss"): streams GeoLocation to the client like the regular GNSS sensor, but on the ROS2 side publishes the sensor pose in the map frame (world transform + MGRS offset) as <base>/pose and <base>/pose_with_covariance. More...
#include <AutowareGnssSensor.h>
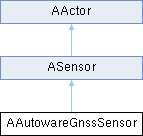
 Inheritance diagram for AAutowareGnssSensor:
Public Member Functions | |
| AAutowareGnssSensor (const FObjectInitializer &ObjectInitializer) | |
| float | GetAltitudeBias () const |
| float | GetAltitudeDeviation () const |
| double | GetAltitudeValue () const |
| float | GetLatitudeBias () const |
| float | GetLatitudeDeviation () const |
| double | GetLatitudeValue () const |
| float | GetLongitudeBias () const |
| float | GetLongitudeDeviation () const |
| double | GetLongitudeValue () const |
| void | GetMirrorState (carla::multigpu::SensorState &State) const override |
| Multi-GPU: the runtime state this sensor starts its next tick from (noise generator, sweep angle, history). | |
| bool | IsNoiseErrorEnabled () const |
| void | LoadMgrsData () |
| void | Set (const FActorDescription &ActorDescription) |
| void | SetAltitudeBias (float Value) |
| void | SetAltitudeDeviation (float Value) |
| void | SetLatitudeBias (float Value) |
| void | SetLatitudeDeviation (float Value) |
| void | SetLongitudeBias (float Value) |
| void | SetLongitudeDeviation (float Value) |
| void | SetMirrorState (const carla::multigpu::SensorState &State) override |
| Public Member Functions inherited from ASensor | |
| bool | AreClientsListening () |
| ASensor (const FObjectInitializer &ObjectInitializer) | |
| void | ClearReadyToTick () |
| std::optional< FActorAttribute > | GetAttribute (const FString Name) |
| const UCarlaEpisode & | GetEpisode () const |
| URandomEngine * | GetRandomEngine () |
| float | GetReadyToTickDeltaSeconds () const |
| int32 | GetSeed () const |
| auto | GetToken () const |
| Return the token that allows subscribing to this sensor's stream. | |
| bool | IsReadyToTick () const |
| bool | IsStreamReady () |
| FDataStream | MoveDataStream () |
| virtual void | OnFirstClientConnected () |
| virtual void | OnLastClientDisconnected () |
| void | PostPhysTickInternal (UWorld *World, ELevelTick TickType, float DeltaSeconds) |
| virtual void | PrePhysTick (float DeltaSeconds) |
| void | SetDataStream (FDataStream InStream) |
| Replace the FDataStream associated with this sensor. | |
| void | SetEpisode (const UCarlaEpisode &InEpisode) |
| void | SetPrimaryTick (float DeltaSeconds) |
| Multi-GPU secondary: tick in this engine frame, with the primary's delta. | |
| void | SetSavingDataToDisk (bool bSavingData) |
| void | SetSeed (int32 InSeed) |
| void | Tick (const float DeltaTime) final |
Static Public Member Functions | |
| static FActorDefinition | GetSensorDefinition () |
| Static Public Member Functions inherited from ASensor | |
| static FSensorCaptureContext | MakeCaptureContext (const ASensor &Sensor) |
| Call on the game thread right after CaptureScene(). | |
Protected Member Functions | |
| virtual void | BeginPlay () override |
| virtual void | PostPhysTick (UWorld *World, ELevelTick TickType, float DeltaSeconds) override |
| void | SetNoiseErrorActive (const bool bEnabled) |
| Protected Member Functions inherited from ASensor | |
| void | EndPlay (EEndPlayReason::Type EndPlayReason) override |
| template<typename SensorType > | |
| FAsyncDataStream | GetDataStream (SensorType &&Self) |
| Return the FDataStream associated with this sensor. | |
| void | PostActorCreated () override |
Private Attributes | |
| float | AltitudeBias |
| float | AltitudeDeviation |
| double | AltitudeValue |
| bool | bApplyNoiseError = false |
| carla::geom::GeoProjection | CurrentGeoProjection |
| float | LatitudeBias |
| float | LatitudeDeviation |
| double | LatitudeValue |
| float | LongitudeBias |
| float | LongitudeDeviation |
| double | LongitudeValue |
| TObjectPtr< UMgrsDataAsset > | MgrsDataAsset = nullptr |
Additional Inherited Members | |
| Static Protected Member Functions inherited from ASensor | |
| template<typename SensorType , typename ElementType > | |
| static void | SendDataToClient (SensorType &&Sensor, TArrayView< ElementType > SensorData, const FSensorCaptureContext &CaptureContext) |
| Protected Attributes inherited from ASensor | |
| bool | bIsActive = false |
| bool | bSavingDataToDisk = false |
| URandomEngine * | RandomEngine = nullptr |
| Random Engine used to provide noise for sensor output. | |
| int32 | Seed = 123456789 |
| Seed of the pseudo-random engine. | |
Detailed Description
Autoware GNSS sensor ("sensor.other.autoware_gnss"): streams GeoLocation to the client like the regular GNSS sensor, but on the ROS2 side publishes the sensor pose in the map frame (world transform + MGRS offset) as <base>/pose and <base>/pose_with_covariance.
Ported from tier4/autoware-support.
Definition at line 27 of file AutowareGnssSensor.h.
Constructor & Destructor Documentation
◆ AAutowareGnssSensor()
| AAutowareGnssSensor::AAutowareGnssSensor | ( | const FObjectInitializer & | ObjectInitializer | ) |
Definition at line 21 of file AutowareGnssSensor.cpp.
References ASensor::RandomEngine.
Member Function Documentation
◆ BeginPlay()
|
overrideprotectedvirtual |
Reimplemented from ASensor.
Definition at line 33 of file AutowareGnssSensor.cpp.
References CurrentGeoProjection, UCarlaStatics::GetCurrentEpisode(), UCarlaEpisode::GetGeoProjection(), and LoadMgrsData().
◆ GetAltitudeBias()
| float AAutowareGnssSensor::GetAltitudeBias | ( | ) | const |
Definition at line 193 of file AutowareGnssSensor.cpp.
References AltitudeBias.
◆ GetAltitudeDeviation()
| float AAutowareGnssSensor::GetAltitudeDeviation | ( | ) | const |
Definition at line 180 of file AutowareGnssSensor.cpp.
References AltitudeDeviation.
◆ GetAltitudeValue()
| double AAutowareGnssSensor::GetAltitudeValue | ( | ) | const |
Definition at line 208 of file AutowareGnssSensor.cpp.
References AltitudeValue.
◆ GetLatitudeBias()
| float AAutowareGnssSensor::GetLatitudeBias | ( | ) | const |
Definition at line 185 of file AutowareGnssSensor.cpp.
References LatitudeBias.
◆ GetLatitudeDeviation()
| float AAutowareGnssSensor::GetLatitudeDeviation | ( | ) | const |
Definition at line 172 of file AutowareGnssSensor.cpp.
References LatitudeDeviation.
◆ GetLatitudeValue()
| double AAutowareGnssSensor::GetLatitudeValue | ( | ) | const |
Definition at line 198 of file AutowareGnssSensor.cpp.
References LatitudeValue.
◆ GetLongitudeBias()
| float AAutowareGnssSensor::GetLongitudeBias | ( | ) | const |
Definition at line 189 of file AutowareGnssSensor.cpp.
References LongitudeBias.
◆ GetLongitudeDeviation()
| float AAutowareGnssSensor::GetLongitudeDeviation | ( | ) | const |
Definition at line 176 of file AutowareGnssSensor.cpp.
References LongitudeDeviation.
◆ GetLongitudeValue()
| double AAutowareGnssSensor::GetLongitudeValue | ( | ) | const |
Definition at line 203 of file AutowareGnssSensor.cpp.
References LongitudeValue.
◆ GetMirrorState()
|
overridevirtual |
Multi-GPU: the runtime state this sensor starts its next tick from (noise generator, sweep angle, history).
Override only for sensors whose PostPhysTick runs whether or not anyone listens: the primary's sensor owns the state of a sensor computed by a secondary.
Reimplemented from ASensor.
Definition at line 223 of file AutowareGnssSensor.cpp.
References URandomEngine::GetState(), ASensor::RandomEngine, and State.
◆ GetSensorDefinition()
|
static |
Definition at line 28 of file AutowareGnssSensor.cpp.
References UActorBlueprintFunctionLibrary::MakeAutowareGnssDefinition().
◆ IsNoiseErrorEnabled()
| bool AAutowareGnssSensor::IsNoiseErrorEnabled | ( | ) | const |
Definition at line 213 of file AutowareGnssSensor.cpp.
References bApplyNoiseError.
◆ LoadMgrsData()
| void AAutowareGnssSensor::LoadMgrsData | ( | ) |
Definition at line 111 of file AutowareGnssSensor.cpp.
References IsValid(), and MgrsDataAsset.
Referenced by BeginPlay().
◆ PostPhysTick()
|
overrideprotectedvirtual |
Reimplemented from ASensor.
Definition at line 44 of file AutowareGnssSensor.cpp.
References carla::geom::GeoLocation::altitude, AltitudeBias, AltitudeDeviation, AltitudeValue, bApplyNoiseError, CurrentGeoProjection, carla::streaming::detail::token_type::get_stream_id(), ASensor::GetDataStream(), carla::ros2::ROS2::GetInstance(), UCarlaStatics::GetLargeMapManager(), URandomEngine::GetNormalDistribution(), ASensor::GetToken(), carla::geom::GeoLocation::latitude, LatitudeBias, LatitudeDeviation, LatitudeValue, ALargeMapManager::LocalToGlobalLocation(), carla::geom::GeoLocation::longitude, LongitudeBias, LongitudeDeviation, LongitudeValue, MgrsDataAsset, PostPhysTick(), ASensor::RandomEngine, and carla::geom::GeoProjection::TransformToGeoLocation().
Referenced by PostPhysTick().
◆ Set()
|
virtual |
Reimplemented from ASensor.
Definition at line 136 of file AutowareGnssSensor.cpp.
References UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetAltitudeBias()
| void AAutowareGnssSensor::SetAltitudeBias | ( | float | Value | ) |
Definition at line 167 of file AutowareGnssSensor.cpp.
References AltitudeBias.
Referenced by UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetAltitudeDeviation()
| void AAutowareGnssSensor::SetAltitudeDeviation | ( | float | Value | ) |
Definition at line 152 of file AutowareGnssSensor.cpp.
References AltitudeDeviation.
Referenced by UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetLatitudeBias()
| void AAutowareGnssSensor::SetLatitudeBias | ( | float | Value | ) |
Definition at line 157 of file AutowareGnssSensor.cpp.
References LatitudeBias.
Referenced by UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetLatitudeDeviation()
| void AAutowareGnssSensor::SetLatitudeDeviation | ( | float | Value | ) |
Definition at line 142 of file AutowareGnssSensor.cpp.
References LatitudeDeviation.
Referenced by UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetLongitudeBias()
| void AAutowareGnssSensor::SetLongitudeBias | ( | float | Value | ) |
Definition at line 162 of file AutowareGnssSensor.cpp.
References LongitudeBias.
Referenced by UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetLongitudeDeviation()
| void AAutowareGnssSensor::SetLongitudeDeviation | ( | float | Value | ) |
Definition at line 147 of file AutowareGnssSensor.cpp.
References LongitudeDeviation.
Referenced by UActorBlueprintFunctionLibrary::SetAutowareGnss().
◆ SetMirrorState()
|
overridevirtual |
Reimplemented from ASensor.
Definition at line 231 of file AutowareGnssSensor.cpp.
References ASensor::RandomEngine, URandomEngine::SetState(), and State.
◆ SetNoiseErrorActive()
|
protected |
Definition at line 218 of file AutowareGnssSensor.cpp.
References bApplyNoiseError.
Member Data Documentation
◆ AltitudeBias
|
private |
Definition at line 93 of file AutowareGnssSensor.h.
Referenced by GetAltitudeBias(), PostPhysTick(), and SetAltitudeBias().
◆ AltitudeDeviation
|
private |
Definition at line 89 of file AutowareGnssSensor.h.
Referenced by GetAltitudeDeviation(), PostPhysTick(), and SetAltitudeDeviation().
◆ AltitudeValue
|
private |
Definition at line 97 of file AutowareGnssSensor.h.
Referenced by GetAltitudeValue(), and PostPhysTick().
◆ bApplyNoiseError
|
private |
Definition at line 85 of file AutowareGnssSensor.h.
Referenced by IsNoiseErrorEnabled(), PostPhysTick(), and SetNoiseErrorActive().
◆ CurrentGeoProjection
|
private |
Definition at line 83 of file AutowareGnssSensor.h.
Referenced by BeginPlay(), and PostPhysTick().
◆ LatitudeBias
|
private |
Definition at line 91 of file AutowareGnssSensor.h.
Referenced by GetLatitudeBias(), PostPhysTick(), and SetLatitudeBias().
◆ LatitudeDeviation
|
private |
Definition at line 87 of file AutowareGnssSensor.h.
Referenced by GetLatitudeDeviation(), PostPhysTick(), and SetLatitudeDeviation().
◆ LatitudeValue
|
private |
Definition at line 95 of file AutowareGnssSensor.h.
Referenced by GetLatitudeValue(), and PostPhysTick().
◆ LongitudeBias
|
private |
Definition at line 92 of file AutowareGnssSensor.h.
Referenced by GetLongitudeBias(), PostPhysTick(), and SetLongitudeBias().
◆ LongitudeDeviation
|
private |
Definition at line 88 of file AutowareGnssSensor.h.
Referenced by GetLongitudeDeviation(), PostPhysTick(), and SetLongitudeDeviation().
◆ LongitudeValue
|
private |
Definition at line 96 of file AutowareGnssSensor.h.
Referenced by GetLongitudeValue(), and PostPhysTick().
◆ MgrsDataAsset
|
private |
Definition at line 81 of file AutowareGnssSensor.h.
Referenced by LoadMgrsData(), and PostPhysTick().
The documentation for this class was generated from the following files:
