#include <LaneInvasionSensor.h>
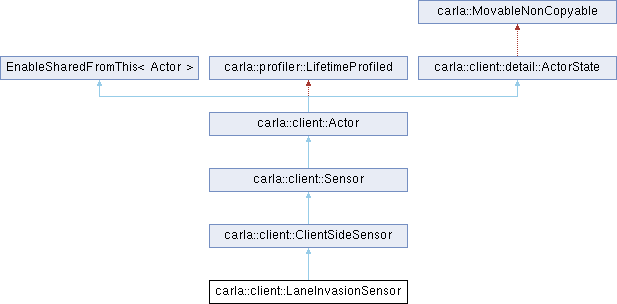
 Inheritance diagram for carla::client::LaneInvasionSensor:
Public Member Functions | |
| bool | IsListening () const override |
| Return whether this Sensor instance is currently listening to the associated sensor in the simulator. | |
| void | Listen (CallbackFunctionType callback) override |
| Register a callback to be executed each time a new measurement is received. | |
| void | Stop () override |
| Stop listening for new measurements. | |
| ~LaneInvasionSensor () | |
| Public Member Functions inherited from carla::client::Sensor | |
| Actor (ActorInitializer init) | |
| Public Member Functions inherited from carla::client::Actor | |
| Actor (ActorInitializer init) | |
| void | AddAngularImpulse (const geom::Vector3D &vector) |
| Add angular impulse to the actor. | |
| void | AddForce (const geom::Vector3D &force) |
| Add force to the actor at its center of mass. | |
| void | AddForce (const geom::Vector3D &force, const geom::Vector3D &location) |
| Add force to the actor at certain location. | |
| void | AddImpulse (const geom::Vector3D &impulse, const geom::Vector3D &location) |
| Add impulse to the actor at certain location. | |
| void | AddImpulse (const geom::Vector3D &vector) |
| Add impulse to the actor at its center of mass. | |
| void | AddTorque (const geom::Vector3D &vector) |
| Add a torque to the actor. | |
| void | ApplyTexture (const rpc::MaterialParameter &MaterialParameter, const rpc::TextureColor &Texture) |
| void | ApplyTexture (const rpc::MaterialParameter &MaterialParameter, const rpc::TextureFloatColor &Texture) |
| virtual bool | Destroy () |
| Tell the simulator to destroy this Actor, and return whether the actor was successfully destroyed. | |
| void | DisableConstantAcceleration () |
| Disable the constant acceleration mode. | |
| void | DisableConstantVelocity () |
| Disable the constant velocity mode. | |
| void | EnableConstantAcceleration (const geom::Vector3D &vector) |
| Enable a constant acceleration mode (direct acceleration, no pedal input) | |
| void | EnableConstantVelocity (const geom::Vector3D &vector) |
| Enable a constant velocity mode. | |
| geom::Vector3D | GetAcceleration () const |
| Return the current 3D acceleration of the actor. | |
| std::string | GetActorClassName () const |
| Return the name of the underlying actor's Unreal class. | |
| std::string | GetActorName () const |
| Return the name of the underlying Unreal actor. | |
| rpc::ActorState | GetActorState () const |
| geom::Vector3D | GetAngularVelocity () const |
| Return the current 3D angular velocity of the actor. | |
| std::vector< std::string > | GetBoneNames () const |
| Return the names of every bone reachable from the actor's first skinned mesh component. | |
| std::vector< geom::Transform > | GetBoneRelativeTransforms () const |
| Return the component-space transforms of every bone reachable from the actor's skinned mesh components. | |
| std::vector< geom::Transform > | GetBoneWorldTransforms () const |
| Return the world-space transforms of every bone reachable from the actor's skinned mesh components. | |
| std::vector< std::string > | GetComponentNames () const |
| Return the names of every actor component attached to the actor. | |
| geom::Transform | GetComponentRelativeTransform (const std::string &component_name) const |
| Return the parent-relative transform of the scene component named component_name attached to the actor. | |
| geom::Transform | GetComponentWorldTransform (const std::string &component_name) const |
| Return the world-space transform of the scene component named component_name attached to the actor. | |
| geom::Location | GetLocation () const |
| Return the current location of the actor. | |
| std::vector< std::string > | GetSocketNames () const |
| Return the names of every socket on every scene component attached to the actor. | |
| std::vector< geom::Transform > | GetSocketRelativeTransforms () const |
| Return the actor-relative transforms of every socket on every scene component attached to the actor. | |
| std::vector< geom::Transform > | GetSocketWorldTransforms () const |
| Return the world-space transforms of every socket on every scene component attached to the actor. | |
| geom::Transform | GetTransform () const |
| Return the current transform of the actor. | |
| geom::Vector3D | GetVelocity () const |
| Return the current 3D velocity of the actor. | |
| bool | IsActive () const |
| bool | IsAlive () const |
| bool | IsDormant () const |
| const auto & | Serialize () const |
| void | SetActorDead () |
| Set actor as dead and starts his life span. | |
| void | SetCollisions (bool enabled=true) |
| Enable or disable collisions on this actor. | |
| void | SetEnableGravity (bool enabled=true) |
| Enable or disable gravity on this actor. | |
| void | SetLocation (const geom::Location &location) |
| Teleport the actor to location. | |
| void | SetSimulatePhysics (bool enabled=true) |
| Enable or disable physics simulation on this actor. | |
| void | SetTargetAngularVelocity (const geom::Vector3D &vector) |
| Set the angular velocity of the actor before applying physics. | |
| void | SetTargetVelocity (const geom::Vector3D &vector) |
| Set the actor velocity before applying physics. | |
| void | SetTransform (const geom::Transform &transform) |
| Teleport and rotate the actor to transform. | |
| virtual | ~Actor ()=default |
| Public Member Functions inherited from carla::client::detail::ActorState | |
| const std::vector< ActorAttributeValue > & | GetAttributes () const |
| const std::string & | GetDisplayId () const |
| ActorId | GetId () const |
| SharedPtr< Actor > | GetParent () const |
| ActorId | GetParentId () const |
| const std::vector< uint8_t > & | GetSemanticTags () const |
| uint64_t | GetSpawnFrame () const |
| Frame of the last world snapshot this client had received when the spawn of this actor was acknowledged by the server; unset for looked-up handles. | |
| const std::string & | GetTypeId () const |
| World | GetWorld () const |
| bool | WasSpawnedByThisClient () const |
| Whether this handle was returned by a spawn call of this client, as opposed to being looked up (get_actor, get_actors, parent, spectator). | |
Private Attributes | |
| std::atomic_size_t | _callback_id {0u} |
Additional Inherited Members | |
| Public Types inherited from carla::client::Sensor | |
| using | CallbackFunctionType = std::function< void(SharedPtr< sensor::SensorData >)> |
| Protected Member Functions inherited from carla::client::detail::ActorState | |
| ActorState (rpc::Actor description, EpisodeProxy episode) | |
| const rpc::Actor & | GetActorDescription () const |
| const geom::BoundingBox & | GetBoundingBox () const |
| EpisodeProxy & | GetEpisode () |
| const EpisodeProxy & | GetEpisode () const |
Detailed Description
Definition at line 19 of file LibCarla/source/carla/client/LaneInvasionSensor.h.
Constructor & Destructor Documentation
◆ ~LaneInvasionSensor()
| carla::client::LaneInvasionSensor::~LaneInvasionSensor | ( | ) |
Definition at line 142 of file LibCarla/source/carla/client/LaneInvasionSensor.cpp.
References Stop().
Member Function Documentation
◆ IsListening()
|
inlineoverridevirtual |
Return whether this Sensor instance is currently listening to the associated sensor in the simulator.
Implements carla::client::Sensor.
Definition at line 40 of file LibCarla/source/carla/client/LaneInvasionSensor.h.
References _callback_id.
◆ Listen()
|
overridevirtual |
Register a callback to be executed each time a new measurement is received.
- Warning
- Calling this function on a sensor that is already listening steals the data stream from the previously set callback. Note that several instances of Sensor (even in different processes) may point to the same sensor in the simulator.
Implements carla::client::Sensor.
Definition at line 146 of file LibCarla/source/carla/client/LaneInvasionSensor.cpp.
References _callback_id, carla::client::detail::ActorState::GetDisplayId(), carla::client::detail::ActorState::GetEpisode(), carla::client::detail::ActorState::GetParent(), carla::client::detail::EpisodeProxyImpl< PointerT >::Lock(), and carla::log_error().
◆ Stop()
|
overridevirtual |
Stop listening for new measurements.
Implements carla::client::Sensor.
Definition at line 174 of file LibCarla/source/carla/client/LaneInvasionSensor.cpp.
References _callback_id, carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::TryLock().
Referenced by ~LaneInvasionSensor().
Member Data Documentation
◆ _callback_id
|
private |
Definition at line 46 of file LibCarla/source/carla/client/LaneInvasionSensor.h.
Referenced by IsListening(), Listen(), and Stop().
The documentation for this class was generated from the following files:
