A fixed-sweep ray-cast Lidar approximating a Hybrid Solid-State LiDAR (e.g. More...
#include <HSSLidar.h>
 Inheritance diagram for AHSSLidar:
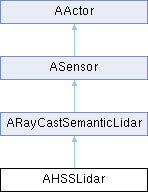
Public Member Functions | |
| AHSSLidar (const FObjectInitializer &ObjectInitializer) | |
| const TArray< float > & | GetTestPointCloud () const |
| virtual void | SendData (const float DeltaTime) override |
| virtual void | Set (const FActorDescription &Description) override |
| virtual void | Set (const FLidarDescription &LidarDescription) override |
| virtual void | SimulateLidar (const float DeltaTime, bool bLockPhysics=true) override |
| Public Member Functions inherited from ARayCastSemanticLidar | |
| ARayCastSemanticLidar (const FObjectInitializer &ObjectInitializer) | |
| void | GetMirrorState (carla::multigpu::SensorState &State) const override |
| Multi-GPU: the runtime state this sensor starts its next tick from (noise generator, sweep angle, history). | |
| void | SetMirrorState (const carla::multigpu::SensorState &State) override |
| Public Member Functions inherited from ASensor | |
| bool | AreClientsListening () |
| ASensor (const FObjectInitializer &ObjectInitializer) | |
| void | ClearReadyToTick () |
| std::optional< FActorAttribute > | GetAttribute (const FString Name) |
| const UCarlaEpisode & | GetEpisode () const |
| URandomEngine * | GetRandomEngine () |
| float | GetReadyToTickDeltaSeconds () const |
| int32 | GetSeed () const |
| auto | GetToken () const |
| Return the token that allows subscribing to this sensor's stream. | |
| bool | IsReadyToTick () const |
| bool | IsStreamReady () |
| FDataStream | MoveDataStream () |
| virtual void | OnFirstClientConnected () |
| virtual void | OnLastClientDisconnected () |
| virtual void | PostPhysTick (UWorld *World, ELevelTick TickType, float DeltaSeconds) |
| void | PostPhysTickInternal (UWorld *World, ELevelTick TickType, float DeltaSeconds) |
| virtual void | PrePhysTick (float DeltaSeconds) |
| void | SetDataStream (FDataStream InStream) |
| Replace the FDataStream associated with this sensor. | |
| void | SetEpisode (const UCarlaEpisode &InEpisode) |
| void | SetPrimaryTick (float DeltaSeconds) |
| Multi-GPU secondary: tick in this engine frame, with the primary's delta. | |
| void | SetSavingDataToDisk (bool bSavingData) |
| void | SetSeed (int32 InSeed) |
| void | Tick (const float DeltaTime) final |
Static Public Member Functions | |
| static FActorDefinition | GetSensorDefinition () |
| Static Public Member Functions inherited from ARayCastSemanticLidar | |
| static FActorDefinition | GetSensorDefinition () |
| Static Public Member Functions inherited from ASensor | |
| static FSensorCaptureContext | MakeCaptureContext (const ASensor &Sensor) |
| Call on the game thread right after CaptureScene(). | |
Private Types | |
| using | FDetection = carla::sensor::data::LidarDetection |
| using | FLidarData = carla::sensor::data::LidarData |
Private Member Functions | |
| void | ComputeAndSaveDetections (const FTransform &SensorTransform) override |
| Copies the per-channel detections into the LidarData structure. | |
| FDetection | ComputeDetection (const FHitResult &HitInfo, const FTransform &InverseSensorTransform) const |
| bool | PostprocessDetection (FDetection &Detection) const |
| void | PreprocessRays (uint32_t Channels, uint32_t MaxPointsPerChannel) override |
| Method that allow to preprocess if the rays will be traced. | |
| void | ResetDetections (uint32_t Channels, uint32_t MaxPointsPerChannel) override |
| Clear the per-channel detection buffers. | |
| void | WriteDetectionAsync (uint32_t Channel, const FHitResult &HitInfo, const FTransform &InverseSensorTransform, const FVector &SensorLocation) override |
| Computes the detection of a hit inside the raycast ParallelFor. | |
Private Attributes | |
| std::vector< std::vector< FDetection > > | Detections |
| float | DropOffAlpha |
| Slope for the intensity dropoff of lidar points: alpha*Intensity + beta where alpha = dropoff_zero_intensity / dropoff_limit and beta = 1 - dropoff_zero_intensity. | |
| float | DropOffBeta |
| bool | DropOffGenActive |
| Enable/Disable general dropoff of lidar points. | |
| FLidarData | LidarData |
| TArray< float > | PointCloudLidarData |
| WITH_EDITOR-only mirror of the point cloud, used by the debug save path. | |
Additional Inherited Members | |
| Protected Types inherited from ARayCastSemanticLidar | |
| using | FSemanticDetection = carla::sensor::data::SemanticLidarDetection |
| using | FSemanticLidarData = carla::sensor::data::SemanticLidarData |
| Protected Member Functions inherited from ARayCastSemanticLidar | |
| virtual void | BeginPlay () override |
| void | ComputeRawDetection (const FHitResult &HitInfo, const FTransform &InverseSensorTransform, const FVector &SensorLocation, FSemanticDetection &Detection) const |
| Compute all raw detection information. | |
| void | CreateLasers () |
| Creates a Laser for each channel. | |
| virtual void | EndPlay (EEndPlayReason::Type EndPlayReason) override |
| bool | ShootLaser (const float VerticalAngle, float HorizontalAngle, FHitResult &HitResult, FCollisionQueryParams &TraceParams, const FVector &LidarBodyLocation, const FRotator &LidarBodyRotation) const |
| Shoot a laser ray-trace, return whether the laser hit something. | |
| Protected Member Functions inherited from ASensor | |
| void | EndPlay (EEndPlayReason::Type EndPlayReason) override |
| template<typename SensorType > | |
| FAsyncDataStream | GetDataStream (SensorType &&Self) |
| Return the FDataStream associated with this sensor. | |
| void | PostActorCreated () override |
| Static Protected Member Functions inherited from ARayCastSemanticLidar | |
| template<typename DetectionT , typename LidarDataT , typename PostprocessT > | |
| static void | CompactAndWriteDetections (std::vector< std::vector< DetectionT > > &Detections, std::vector< uint32_t > &OutPointsPerChannel, uint32_t Channels, LidarDataT &LidarData, PostprocessT &&Postprocess) |
| Post-processes the detections channel by channel, drops the rejected ones and writes the rest to LidarData. | |
| template<typename DetectionT > | |
| static void | CopyDetectionsToPointCloud (const std::vector< std::vector< DetectionT > > &Detections, const std::vector< uint32_t > &InPointsPerChannel, TArray< float > &PointCloud) |
| Copies the kept detections into a flat x, y, z, intensity array (editor debug point cloud). | |
| template<typename DetectionT > | |
| static void | ResetChannelDetections (std::vector< std::vector< DetectionT > > &Detections, uint32_t Channels, uint32_t MaxPointsPerChannel) |
| Clears every channel buffer and reserves room for a full scan. | |
| Static Protected Member Functions inherited from ASensor | |
| template<typename SensorType , typename ElementType > | |
| static void | SendDataToClient (SensorType &&Sensor, TArrayView< ElementType > SensorData, const FSensorCaptureContext &CaptureContext) |
| Protected Attributes inherited from ARayCastSemanticLidar | |
| FLidarDescription | Description |
| TArray< float > | LaserAngles |
| std::vector< uint32_t > | PointsPerChannel |
| std::vector< std::vector< bool > > | RayPreprocessCondition |
| Protected Attributes inherited from ASensor | |
| bool | bIsActive = false |
| bool | bSavingDataToDisk = false |
| URandomEngine * | RandomEngine = nullptr |
| Random Engine used to provide noise for sensor output. | |
| int32 | Seed = 123456789 |
| Seed of the pseudo-random engine. | |
Detailed Description
A fixed-sweep ray-cast Lidar approximating a Hybrid Solid-State LiDAR (e.g.
Hesai AT128). Unlike ARayCastLidar this sensor does not rotate; each tick it casts a configurable horizontal field of view at a fixed angular resolution centred on the sensor's forward axis.
Definition at line 27 of file HSSLidar.h.
Member Typedef Documentation
◆ FDetection
|
private |
Definition at line 32 of file HSSLidar.h.
◆ FLidarData
|
private |
Definition at line 31 of file HSSLidar.h.
Constructor & Destructor Documentation
◆ AHSSLidar()
| AHSSLidar::AHSSLidar | ( | const FObjectInitializer & | ObjectInitializer | ) |
Definition at line 35 of file HSSLidar.cpp.
References ARayCastSemanticLidar::Description, ASensor::RandomEngine, FLidarDescription::RandomSeed, and ASensor::SetSeed().
Member Function Documentation
◆ ComputeAndSaveDetections()
|
overrideprivatevirtual |
Copies the per-channel detections into the LidarData structure.
Reimplemented from ARayCastSemanticLidar.
Definition at line 166 of file HSSLidar.cpp.
References ASensor::bSavingDataToDisk, FLidarDescription::Channels, ARayCastSemanticLidar::CompactAndWriteDetections(), ARayCastSemanticLidar::CopyDetectionsToPointCloud(), ARayCastSemanticLidar::Description, Detections, LidarData, PointCloudLidarData, and ARayCastSemanticLidar::PointsPerChannel.
Referenced by SimulateLidar().
◆ ComputeDetection()
|
private |
Definition at line 104 of file HSSLidar.cpp.
References FLidarDescription::AtmospAttenRate, ARayCastSemanticLidar::Description, carla::sensor::data::LidarDetection::intensity, carla::geom::Vector3D::Length(), and carla::sensor::data::LidarDetection::point.
Referenced by WriteDetectionAsync().
◆ GetSensorDefinition()
|
static |
Definition at line 30 of file HSSLidar.cpp.
References UActorBlueprintFunctionLibrary::MakeLidarDefinition().
◆ GetTestPointCloud()
|
inline |
Definition at line 43 of file HSSLidar.h.
◆ PostprocessDetection()
|
private |
Definition at line 140 of file HSSLidar.cpp.
References ARayCastSemanticLidar::Description, DropOffAlpha, DropOffBeta, FLidarDescription::DropOffIntensityLimit, URandomEngine::GetNormalDistribution(), URandomEngine::GetUniformFloat(), carla::sensor::data::LidarDetection::intensity, carla::geom::Vector3D::MakeUnitVector(), FLidarDescription::NoiseStdDev, carla::sensor::data::LidarDetection::point, and ASensor::RandomEngine.
◆ PreprocessRays()
|
overrideprivatevirtual |
Method that allow to preprocess if the rays will be traced.
Reimplemented from ARayCastSemanticLidar.
Definition at line 123 of file HSSLidar.cpp.
References ARayCastSemanticLidar::Description, DropOffGenActive, FLidarDescription::DropOffGenRate, URandomEngine::GetUniformFloat(), ASensor::RandomEngine, and ARayCastSemanticLidar::RayPreprocessCondition.
Referenced by SimulateLidar().
◆ ResetDetections()
|
overrideprivatevirtual |
Clear the per-channel detection buffers.
Reimplemented from ARayCastSemanticLidar.
Definition at line 155 of file HSSLidar.cpp.
References Detections, and ARayCastSemanticLidar::ResetChannelDetections().
Referenced by SimulateLidar().
◆ SendData()
|
overridevirtual |
Reimplemented from ARayCastSemanticLidar.
Definition at line 73 of file HSSLidar.cpp.
References carla::streaming::detail::token_type::get_stream_id(), ASensor::GetDataStream(), carla::ros2::ROS2::GetInstance(), ASensor::GetToken(), LidarData, and SendData().
Referenced by SendData().
◆ Set() [1/2]
|
overridevirtual |
Reimplemented from ARayCastSemanticLidar.
Definition at line 42 of file HSSLidar.cpp.
References ASensor::Set(), Set(), and UActorBlueprintFunctionLibrary::SetLidar().
Referenced by Set().
◆ Set() [2/2]
|
overridevirtual |
Reimplemented from ARayCastSemanticLidar.
Definition at line 50 of file HSSLidar.cpp.
References FLidarDescription::Channels, ARayCastSemanticLidar::CreateLasers(), ARayCastSemanticLidar::Description, DropOffAlpha, FLidarDescription::DropOffAtZeroIntensity, DropOffBeta, DropOffGenActive, FLidarDescription::DropOffGenRate, FLidarDescription::DropOffIntensityLimit, LidarData, ARayCastSemanticLidar::PointsPerChannel, FLidarDescription::RandomSeed, and ASensor::SetSeed().
◆ SimulateLidar()
|
overridevirtual |
Reimplemented from ARayCastSemanticLidar.
Definition at line 191 of file HSSLidar.cpp.
References FLidarDescription::Channels, ComputeAndSaveDetections(), ARayCastSemanticLidar::Description, FLidarDescription::HorizontalFov, FLidarDescription::HorizontalResolution, ARayCastSemanticLidar::LaserAngles, PreprocessRays(), ARayCastSemanticLidar::RayPreprocessCondition, ResetDetections(), ARayCastSemanticLidar::ShootLaser(), SimulateLidar(), SnapToStep(), and WriteDetectionAsync().
Referenced by SimulateLidar().
◆ WriteDetectionAsync()
|
overrideprivatevirtual |
Computes the detection of a hit inside the raycast ParallelFor.
Reimplemented from ARayCastSemanticLidar.
Definition at line 160 of file HSSLidar.cpp.
References ComputeDetection(), DEBUG_ASSERT, and Detections.
Referenced by SimulateLidar().
Member Data Documentation
◆ Detections
|
private |
Definition at line 59 of file HSSLidar.h.
Referenced by ComputeAndSaveDetections(), ResetDetections(), and WriteDetectionAsync().
◆ DropOffAlpha
|
private |
Slope for the intensity dropoff of lidar points: alpha*Intensity + beta where alpha = dropoff_zero_intensity / dropoff_limit and beta = 1 - dropoff_zero_intensity.
Definition at line 67 of file HSSLidar.h.
Referenced by PostprocessDetection(), and Set().
◆ DropOffBeta
|
private |
Definition at line 68 of file HSSLidar.h.
Referenced by PostprocessDetection(), and Set().
◆ DropOffGenActive
|
private |
Enable/Disable general dropoff of lidar points.
Definition at line 62 of file HSSLidar.h.
Referenced by PreprocessRays(), and Set().
◆ LidarData
|
private |
Definition at line 57 of file HSSLidar.h.
Referenced by ComputeAndSaveDetections(), SendData(), and Set().
◆ PointCloudLidarData
|
private |
WITH_EDITOR-only mirror of the point cloud, used by the debug save path.
Definition at line 71 of file HSSLidar.h.
Referenced by ComputeAndSaveDetections().
The documentation for this class was generated from the following files:
