Base class for CARLA wheeled vehicles. More...
#include <CarlaWheeledVehicleNW.h>
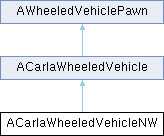
 Inheritance diagram for ACarlaWheeledVehicleNW:
Public Member Functions | |
Constructor and destructor | |
| ACarlaWheeledVehicleNW (const FObjectInitializer &ObjectInitializer) | |
| ~ACarlaWheeledVehicleNW () | |
| Public Member Functions inherited from ACarlaWheeledVehicle | |
| ACarlaWheeledVehicle (const FObjectInitializer &ObjectInitializer) | |
| ~ACarlaWheeledVehicle () | |
| UChaosWheeledVehicleMovementComponent * | GetChaosWheeledVehicleMovementComponent () const |
| Get chaos wheeled vehicle movement component casted. | |
| const FVehicleControl & | GetVehicleControl () const |
| Vehicle control currently applied to this vehicle. | |
| const FVehicleAckermannControl & | GetVehicleAckermannControl () const |
| Vehicle Ackermann control currently applied to this vehicle. | |
| FTransform | GetVehicleTransform () const |
| Transform of the vehicle. | |
| float | GetVehicleForwardSpeed () const |
| Forward speed in cm/s. Might be negative if goes backwards. | |
| FVector | GetVehicleOrientation () const |
| Orientation vector of the vehicle, pointing forward. | |
| int32 | GetVehicleCurrentGear () const |
| Active gear of the vehicle. | |
| FTransform | GetVehicleBoundingBoxTransform () const |
| Transform of the vehicle's bounding box relative to the vehicle. | |
| FVector | GetVehicleBoundingBoxExtent () const |
| Extent of the vehicle's bounding box. | |
| UBoxComponent * | GetVehicleBoundingBox () const |
| Get vehicle's bounding box component. | |
| float | GetMaximumSteerAngle () const |
| Get the maximum angle at which the front wheel can steer. | |
| void | ApplyVehicleControl (const FVehicleControl &Control, EVehicleInputPriority Priority) |
| void | ApplyVehicleAckermannControl (const FVehicleAckermannControl &AckermannControl, EVehicleInputPriority Priority) |
| bool | IsAckermannControlActive () const |
| void | ActivateVelocityControl (const FVector &Velocity) |
| void | DeactivateVelocityControl () |
| void | ActivateAccelerationControl (const FVector &Acceleration) |
| void | DeactivateAccelerationControl () |
| void | ApplyVehicleAccelerationControl (float LongitudinalAccelerationMps2, float Steer, float SteerSpeed) |
| Apply control from Autoware /control/command/control_cmd (acceleration [m/s^2] + steering) | |
| void | ShowDebugTelemetry (bool Enabled) |
| void | FlushVehicleControl () |
| void | SetThrottleInput (float Value) |
| void | SetSteeringInput (float Value) |
| void | SetBrakeInput (float Value) |
| void | SetReverse (bool Value) |
| void | ToggleReverse () |
| void | SetHandbrakeInput (bool Value) |
| void | HoldHandbrake () |
| void | ReleaseHandbrake () |
| TArray< float > | GetWheelsFrictionScale () |
| void | SetWheelsFrictionScale (TArray< float > &WheelsFrictionScale) |
| void | SetCarlaMovementComponent (UBaseCarlaMovementComponent *MoementComponent) |
| template<typename T = UBaseCarlaMovementComponent> | |
| T * | GetCarlaMovementComponent () const |
| void | SetAIVehicleState (ECarlaWheeledVehicleState InState) |
| ECarlaWheeledVehicleState | GetAIVehicleState () const |
| FVehiclePhysicsControl | GetVehiclePhysicsControl () const |
| FVehicleTelemetryData | GetVehicleTelemetryData () const |
| Returns a snapshot of the vehicle's runtime telemetry: forward speed, last applied control inputs, engine RPM, current gear, and per-wheel lateral slip, longitudinal slip, and angular velocity sourced from the Chaos vehicle physics state. | |
| FVector | GetCenterOfMass (UChaosWheeledVehicleMovementComponent &VehicleMovComponent) const |
| FAckermannControllerSettings | GetAckermannControllerSettings () const |
| void | RestoreVehiclePhysicsControl () |
| FVehicleLightState | GetVehicleLightState () const |
| void | ApplyVehiclePhysicsControl (const FVehiclePhysicsControl &PhysicsControl) |
| void | SetCenterOfMass (UChaosWheeledVehicleMovementComponent &VehicleMovComponent, const FVehiclePhysicsControl &PhysicsControl) |
| void | ApplyAckermannControllerSettings (const FAckermannControllerSettings &AckermannControllerSettings) |
| void | SetSimulatePhysics (bool enabled) |
| void | SetVehicleLightState (const FVehicleLightState &LightState) |
| void | SetFailureState (const carla::rpc::VehicleFailureState &FailureState) |
| bool | IsTwoWheeledVehicle () |
| virtual bool | IsTwoWheeledVehicle_Implementation () |
| FTransform | GetCachedVehicleSocketWorldTransform (FName SocketName) const |
| Cached, extrapolated world transform of ANY socket on the vehicle mesh (Seat, HandlerLeftSocket, HandlerRightSocket, LeftPedalSocket, RightPedalSocket, ...), captured from OnRiderBoneTransformsFinalized (which fires late enough in the frame to reliably see this frame's real, physics-updated position – confirmed by logging it against the vehicle's actual movement, always smooth, never stale). | |
| float | GetPedalRotation () const |
| Two-wheeled vehicles spin a decorative pedal/crank bone (in the vehicle mesh's own Anim Blueprint, unrelated to the rider) via a looping Timeline whose curve doesn't start and end at the same value – every loop the Timeline restarts, the bone's rotation pops instantly back to the curve's start value instead of continuing smoothly, and the rider's foot IK (which targets a socket on that bone) pops along with it. | |
| void | PrintROS2Message (const char *Message) |
| FBox | GetDetectionBox () const |
| float | GetDetectionSize () const |
| void | UpdateDetectionBox () |
| const TArray< int32 > | GetFoliageInstancesCloseToVehicle (const UInstancedStaticMeshComponent *Component) const |
| void | DrawFoliageBoundingBox () const |
| FBoxSphereBounds | GetBoxSphereBounds () const |
| bool | IsInVehicleRange (const FVector &Location) const |
| void | SetWheelSteerDirection (EVehicleWheelLocation WheelLocation, float AngleInDeg) |
| Set the rotation of the car wheels indicated by the user 0 = FL_VehicleWheel, 1 = FR_VehicleWheel, 2 = BL_VehicleWheel, 3 = BR_VehicleWheel NOTE : This is purely aesthetic. | |
| float | GetWheelSteerAngle (EVehicleWheelLocation WheelLocation) |
| void | SetWheelPitchAngle (EVehicleWheelLocation WheelLocation, float AngleInDeg) |
| Spin angle of a wheel, in degrees. Purely visual, wheel animation override only. | |
| float | GetWheelPitchAngle (EVehicleWheelLocation WheelLocation) |
| void | SetWheelSuspensionOffset (EVehicleWheelLocation WheelLocation, float OffsetInCm) |
| Suspension compression of a wheel, in cm. | |
| float | GetWheelSuspensionOffset (EVehicleWheelLocation WheelLocation) |
| void | SetWheelAnimationOverride (bool bEnabled) |
| While the wheel animation is overridden the wheels show only the values set through the wheel setters, whether or not Chaos simulates the vehicle. | |
| bool | IsWheelAnimationOverridden () const |
| const TArray< FWheelAnimationData > & | GetOverriddenWheelPoses () const |
| Indexed like the movement component's WheelSetups. | |
| bool | IsSimulatedByChaos () const |
| Whether the Chaos vehicle simulation is moving this vehicle. | |
| bool | HasWheel (int32 WheelIndex) const |
| bool | HasCarlaVehicleAnimation () const |
| Whether the animation blueprint derives from UCarlaVehicleAnimationInstance, which is what draws the overridden wheel poses. | |
| float | GetWheelRadius (int32 WheelIndex) const |
| Radius of the wheel at WheelIndex, in cm, as last applied through the physics control. | |
| FVector | GetWheelSuspensionAxis (int32 WheelIndex) const |
| Unit vector, component space, along which the wheel's suspension drops. | |
| FWheelAnimationData | GetDrawnWheelPose (int32 WheelIndex) const |
| Wheel pose the animation instance drew this frame (else GetWheelPose); what secondaries must draw. | |
| void | OpenDoor (const EVehicleDoor DoorIdx) |
| void | CloseDoor (const EVehicleDoor DoorIdx) |
| void | OpenDoorPhys (const EVehicleDoor DoorIdx) |
| void | CloseDoorPhys (const EVehicleDoor DoorIdx) |
| void | RecordDoorChange (const EVehicleDoor DoorIdx, const bool bIsOpen) |
| TArray< TPair< int32, FTransform > > | GetOpenDoorPoses () const |
| Every door open now (a physics body of its own while open), by door index, with its pose relative to the vehicle. | |
| void | SetMirroredDoorPoses (const TArray< TPair< int32, FTransform > > &OpenDoors) |
| Multi-GPU secondary: shows these doors open, at these poses relative to the vehicle, and every other door closed. | |
| virtual FVector | GetVelocity () const override |
| void | SetMirroredMotion (const FVector &Velocity, float ForwardSpeed) |
| Multi-GPU secondary: the primary's motion of the vehicle this one mirrors (world frame, cm/s), which GetVelocity and GetVehicleForwardSpeed report instead of this body's: a mirror never moves on its own. | |
| void | ClearMirroredMotion () |
| bool | HasMirroredMotion () const |
| void | SetMirroredDrivetrain (int32 Gear, bool bManualGearShift, bool bSimulatingPhysics) |
| Multi-GPU secondary: the primary's gear, which GetVehicleCurrentGear reports instead of the idle drivetrain's, its manual gear shift, and whether the primary's body simulates physics. | |
| bool | GetMirroredManualGearShift () const |
| bool | IsMirroredSimulatingPhysics () const |
| FPoseSnapshot | GetWorldTransformedPose () |
| void | SetRolloverFlag () |
| carla::rpc::VehicleFailureState | GetFailureState () const |
| float | GetSpeedAnim () const |
| void | SetSpeedAnim (float Speed) |
| float | GetRotationAnim () const |
| void | SetRotationAnim (float Rotation) |
Additional Inherited Members | ||
| Static Public Member Functions inherited from ACarlaWheeledVehicle | ||
| static FRotator | GetPhysicsConstraintAngle (UPhysicsConstraintComponent *Component) | |
| static void | SetPhysicsConstraintAngle (UPhysicsConstraintComponent *Component, const FRotator &NewAngle) | |
| Public Attributes inherited from ACarlaWheeledVehicle | ||
| FName | RiderMeshComponentName = TEXT("SkeletalMesh") | |
| Two-wheeled vehicles (bikes/motorcycles) embed their rider as a SkeletalMeshComponent (named RiderMeshComponentName) meant to sit on VehicleMeshSeatSocketName. | ||
| FName | VehicleMeshSeatSocketName = TEXT("Seat") | |
| float | RiderSeatSmoothingSpeed = 10.0f | |
| Chaos suspension has small, real, high-frequency vertical jitter on the vehicle mesh every frame (visible as the rider's torso/hip bouncing, the seat popping the rider up) – physically real, not a bug, but the seat-lock's hard snap transmits it 1:1 to the rider with zero smoothing. | ||
| FRotator | RiderSeatRelativeRotationOffset = FRotator(0.0f, -90.0f, 15.0f) | |
| The rider mesh's rest pose isn't authored to sit flush with the socket's own local axes – its component template ships with this exact relative rotation baked in (no translation), so the seat-lock composes it on top of the socket's world transform instead of using the bare socket transform, which twisted the pose. | ||
| float | PedalRotationDegreesPerCm = 0.5f | |
| Degrees the pedal bone rotates per centimeter of real vehicle travel (see GetPedalRotation). | ||
| struct { | ||
| FVehicleControl Control | ||
| FVehicleLightState LightState | ||
| EVehicleInputPriority Priority = EVehicleInputPriority::INVALID | ||
| } | InputControl | |
| float | DetectionSize { 750.0f } | |
| FBox | FoliageBoundingBox | |
| TObjectPtr< UBoxComponent > | VehicleBounds | |
| float | CarSimOriginOffset = 150.f | |
| bool | bIsNWVehicle = false | |
| float | SpeedAnim { 0.0f } | |
| float | RotationAnim { 0.0f } | |
| FPoseSnapshot | WorldTransformedPose | |
| Protected Member Functions inherited from ACarlaWheeledVehicle | ||
| virtual void | BeginPlay () override | |
| virtual void | TickActor (float DeltaTime, enum ELevelTick TickType, FActorTickFunction &ThisTickFunction) override | |
| virtual void | EndPlay (const EEndPlayReason::Type EndPlayReason) | |
| void | RefreshLightState (const FVehicleLightState &VehicleLightState) | |
| void | AdjustVehicleBounds () | |
| void | ResetConstraints () | |
| Protected Attributes inherited from ACarlaWheeledVehicle | ||
| TArray< FName > | ConstraintComponentNames | |
| float | DoorOpenStrength = 100.0f | |
Detailed Description
Base class for CARLA wheeled vehicles.
Definition at line 15 of file CarlaWheeledVehicleNW.h.
Constructor & Destructor Documentation
◆ ACarlaWheeledVehicleNW()
| ACarlaWheeledVehicleNW::ACarlaWheeledVehicleNW | ( | const FObjectInitializer & | ObjectInitializer | ) |
Definition at line 11 of file CarlaWheeledVehicleNW.cpp.
References ACarlaWheeledVehicle::bIsNWVehicle.
◆ ~ACarlaWheeledVehicleNW()
| ACarlaWheeledVehicleNW::~ACarlaWheeledVehicleNW | ( | ) |
Definition at line 18 of file CarlaWheeledVehicleNW.cpp.
The documentation for this class was generated from the following files:
