#include <Vehicle.h>
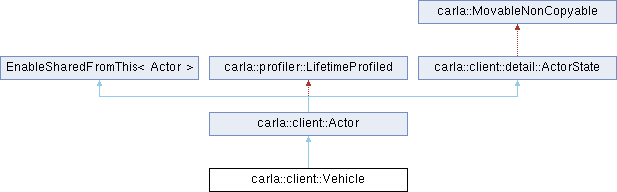
 Inheritance diagram for carla::client::Vehicle:
Public Types | |
| using | AckermannControl = rpc::VehicleAckermannControl |
| using | Control = rpc::VehicleControl |
| using | LightState = rpc::VehicleLightState::LightState |
| using | PhysicsControl = rpc::VehiclePhysicsControl |
| using | TelemetryData = rpc::VehicleTelemetryData |
| using | TM = traffic_manager::TrafficManager |
| using | VehicleDoor = rpc::VehicleDoor |
| using | WheelLocation = carla::rpc::VehicleWheelLocation |
Public Member Functions | |
| void | ApplyAckermannControl (const AckermannControl &control) |
| Apply control to this vehicle. | |
| void | ApplyAckermannControllerSettings (const rpc::AckermannControllerSettings &settings) |
| Apply Ackermann control settings to this vehicle. | |
| void | ApplyControl (const Control &control) |
| Apply control to this vehicle. | |
| void | ApplyPhysicsControl (const PhysicsControl &physics_control) |
| Apply physics control to this vehicle. | |
| void | CloseDoor (const VehicleDoor door_idx) |
| Close a door in this vehicle. | |
| void | EnableCarSim (std::string simfile_path) |
| Enables CarSim simulation if it is availiable. | |
| void | EnableChronoPhysics (uint64_t MaxSubsteps, float MaxSubstepDeltaTime, std::string VehicleJSON="", std::string PowertrainJSON="", std::string TireJSON="", std::string BaseJSONPath="") |
| rpc::AckermannControllerSettings | GetAckermannControllerSettings () const |
| Return the last Ackermann controller settings applied to this vehicle. | |
| Control | GetControl () const |
| Return the control last applied to this vehicle. | |
| rpc::VehicleFailureState | GetFailureState () const |
| Returns the failure state of the vehicle. | |
| LightState | GetLightState () const |
| Return the current open lights (LightState) of this vehicle. | |
| PhysicsControl | GetPhysicsControl () const |
| Return the physics control last applied to this vehicle. | |
| float | GetSpeedLimit () const |
| Return the speed limit currently affecting this vehicle. | |
| TelemetryData | GetTelemetryData () const |
| Return the runtime telemetry of this vehicle: forward speed, last applied control inputs, engine RPM, current gear, and per-wheel lateral slip, longitudinal slip, and angular velocity sourced from the Chaos vehicle physics state. | |
| SharedPtr< TrafficLight > | GetTrafficLight () const |
| Retrieve the traffic light actor currently affecting this vehicle. | |
| rpc::TrafficLightState | GetTrafficLightState () const |
| Return the state of the traffic light currently affecting this vehicle. | |
| std::vector< geom::Transform > | GetVehicleBoneWorldTransforms () const |
| float | GetWheelPitchAngle (WheelLocation wheel_location) |
| Return the spin angle of a wheel, in degrees. | |
| float | GetWheelSteerAngle (WheelLocation wheel_location) |
| Return a Rotation from a wheel of the vehicle. | |
| float | GetWheelSuspensionOffset (WheelLocation wheel_location) |
| Return the suspension compression of a wheel, in meters. | |
| bool | IsAtTrafficLight () |
| Return whether a traffic light is affecting this vehicle. | |
| void | OpenDoor (const VehicleDoor door_idx) |
| Open a door in this vehicle. | |
| void | SetAutopilot (bool enabled=true, uint16_t tm_port=TM_DEFAULT_PORT) |
| Switch on/off this vehicle's autopilot. | |
| void | SetLightState (const LightState &light_state) |
| Sets a LightState to this vehicle. | |
| void | SetWheelAnimationOverride (bool enabled) |
| Enables or disables the wheel animation override, in which the wheels show only the values set through the wheel setters (affects the bones of the car skeleton, not the physics) | |
| void | SetWheelPitchAngle (WheelLocation wheel_location, float angle_in_deg) |
| Sets the spin angle of a wheel, in degrees (affects the bone of the car skeleton, not the physics) | |
| void | SetWheelSteerDirection (WheelLocation wheel_location, float angle_in_deg) |
| Sets a Rotation to a wheel of the vehicle (affects the bone of the car skeleton, not the physics) | |
| void | SetWheelSuspensionOffset (WheelLocation wheel_location, float offset) |
| Sets the suspension compression of a wheel, in meters (affects the bone of the car skeleton, not the physics) | |
| void | ShowDebugTelemetry (bool enabled=true) |
| Switch on/off this vehicle's autopilot. | |
| void | UseCarSimRoad (bool enabled) |
| Enables the use of CarSim internal road definition instead of unreal's. | |
| Vehicle (ActorInitializer init) | |
| Public Member Functions inherited from carla::client::Actor | |
| Actor (ActorInitializer init) | |
| void | AddAngularImpulse (const geom::Vector3D &vector) |
| Add angular impulse to the actor. | |
| void | AddForce (const geom::Vector3D &force) |
| Add force to the actor at its center of mass. | |
| void | AddForce (const geom::Vector3D &force, const geom::Vector3D &location) |
| Add force to the actor at certain location. | |
| void | AddImpulse (const geom::Vector3D &impulse, const geom::Vector3D &location) |
| Add impulse to the actor at certain location. | |
| void | AddImpulse (const geom::Vector3D &vector) |
| Add impulse to the actor at its center of mass. | |
| void | AddTorque (const geom::Vector3D &vector) |
| Add a torque to the actor. | |
| void | ApplyTexture (const rpc::MaterialParameter &MaterialParameter, const rpc::TextureColor &Texture) |
| void | ApplyTexture (const rpc::MaterialParameter &MaterialParameter, const rpc::TextureFloatColor &Texture) |
| virtual bool | Destroy () |
| Tell the simulator to destroy this Actor, and return whether the actor was successfully destroyed. | |
| void | DisableConstantAcceleration () |
| Disable the constant acceleration mode. | |
| void | DisableConstantVelocity () |
| Disable the constant velocity mode. | |
| void | EnableConstantAcceleration (const geom::Vector3D &vector) |
| Enable a constant acceleration mode (direct acceleration, no pedal input) | |
| void | EnableConstantVelocity (const geom::Vector3D &vector) |
| Enable a constant velocity mode. | |
| geom::Vector3D | GetAcceleration () const |
| Return the current 3D acceleration of the actor. | |
| std::string | GetActorClassName () const |
| Return the name of the underlying actor's Unreal class. | |
| std::string | GetActorName () const |
| Return the name of the underlying Unreal actor. | |
| rpc::ActorState | GetActorState () const |
| geom::Vector3D | GetAngularVelocity () const |
| Return the current 3D angular velocity of the actor. | |
| std::vector< std::string > | GetBoneNames () const |
| Return the names of every bone reachable from the actor's first skinned mesh component. | |
| std::vector< geom::Transform > | GetBoneRelativeTransforms () const |
| Return the component-space transforms of every bone reachable from the actor's skinned mesh components. | |
| std::vector< geom::Transform > | GetBoneWorldTransforms () const |
| Return the world-space transforms of every bone reachable from the actor's skinned mesh components. | |
| std::vector< std::string > | GetComponentNames () const |
| Return the names of every actor component attached to the actor. | |
| geom::Transform | GetComponentRelativeTransform (const std::string &component_name) const |
| Return the parent-relative transform of the scene component named component_name attached to the actor. | |
| geom::Transform | GetComponentWorldTransform (const std::string &component_name) const |
| Return the world-space transform of the scene component named component_name attached to the actor. | |
| geom::Location | GetLocation () const |
| Return the current location of the actor. | |
| std::vector< std::string > | GetSocketNames () const |
| Return the names of every socket on every scene component attached to the actor. | |
| std::vector< geom::Transform > | GetSocketRelativeTransforms () const |
| Return the actor-relative transforms of every socket on every scene component attached to the actor. | |
| std::vector< geom::Transform > | GetSocketWorldTransforms () const |
| Return the world-space transforms of every socket on every scene component attached to the actor. | |
| geom::Transform | GetTransform () const |
| Return the current transform of the actor. | |
| geom::Vector3D | GetVelocity () const |
| Return the current 3D velocity of the actor. | |
| bool | IsActive () const |
| bool | IsAlive () const |
| bool | IsDormant () const |
| const auto & | Serialize () const |
| void | SetActorDead () |
| Set actor as dead and starts his life span. | |
| void | SetCollisions (bool enabled=true) |
| Enable or disable collisions on this actor. | |
| void | SetEnableGravity (bool enabled=true) |
| Enable or disable gravity on this actor. | |
| void | SetLocation (const geom::Location &location) |
| Teleport the actor to location. | |
| void | SetSimulatePhysics (bool enabled=true) |
| Enable or disable physics simulation on this actor. | |
| void | SetTargetAngularVelocity (const geom::Vector3D &vector) |
| Set the angular velocity of the actor before applying physics. | |
| void | SetTargetVelocity (const geom::Vector3D &vector) |
| Set the actor velocity before applying physics. | |
| void | SetTransform (const geom::Transform &transform) |
| Teleport and rotate the actor to transform. | |
| virtual | ~Actor ()=default |
| Public Member Functions inherited from carla::client::detail::ActorState | |
| const std::vector< ActorAttributeValue > & | GetAttributes () const |
| const std::string & | GetDisplayId () const |
| ActorId | GetId () const |
| SharedPtr< Actor > | GetParent () const |
| ActorId | GetParentId () const |
| const std::vector< uint8_t > & | GetSemanticTags () const |
| uint64_t | GetSpawnFrame () const |
| Frame of the last world snapshot this client had received when the spawn of this actor was acknowledged by the server; unset for looked-up handles. | |
| const std::string & | GetTypeId () const |
| World | GetWorld () const |
| bool | WasSpawnedByThisClient () const |
| Whether this handle was returned by a spawn call of this client, as opposed to being looked up (get_actor, get_actors, parent, spectator). | |
Private Attributes | |
| Control | _control |
| const bool | _is_control_sticky |
Additional Inherited Members | |
| Protected Member Functions inherited from carla::client::detail::ActorState | |
| ActorState (rpc::Actor description, EpisodeProxy episode) | |
| const rpc::Actor & | GetActorDescription () const |
| const geom::BoundingBox & | GetBoundingBox () const |
| EpisodeProxy & | GetEpisode () |
| const EpisodeProxy & | GetEpisode () const |
Detailed Description
Member Typedef Documentation
◆ AckermannControl
◆ Control
◆ LightState
◆ PhysicsControl
◆ TelemetryData
◆ TM
◆ VehicleDoor
◆ WheelLocation
Constructor & Destructor Documentation
◆ Vehicle()
|
explicit |
Definition at line 34 of file Vehicle.cpp.
Member Function Documentation
◆ ApplyAckermannControl()
| void carla::client::Vehicle::ApplyAckermannControl | ( | const AckermannControl & | control | ) |
Apply control to this vehicle.
Definition at line 58 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ ApplyAckermannControllerSettings()
| void carla::client::Vehicle::ApplyAckermannControllerSettings | ( | const rpc::AckermannControllerSettings & | settings | ) |
Apply Ackermann control settings to this vehicle.
Definition at line 66 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ ApplyControl()
| void carla::client::Vehicle::ApplyControl | ( | const Control & | control | ) |
Apply control to this vehicle.
Definition at line 51 of file Vehicle.cpp.
References _control, _is_control_sticky, carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ ApplyPhysicsControl()
| void carla::client::Vehicle::ApplyPhysicsControl | ( | const PhysicsControl & | physics_control | ) |
Apply physics control to this vehicle.
Definition at line 70 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ CloseDoor()
| void carla::client::Vehicle::CloseDoor | ( | const VehicleDoor | door_idx | ) |
Close a door in this vehicle.
Definition at line 78 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ EnableCarSim()
| void carla::client::Vehicle::EnableCarSim | ( | std::string | simfile_path | ) |
Enables CarSim simulation if it is availiable.
Definition at line 151 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ EnableChronoPhysics()
| void carla::client::Vehicle::EnableChronoPhysics | ( | uint64_t | MaxSubsteps, |
| float | MaxSubstepDeltaTime, | ||
| std::string | VehicleJSON = "", |
||
| std::string | PowertrainJSON = "", |
||
| std::string | TireJSON = "", |
||
| std::string | BaseJSONPath = "" |
||
| ) |
Definition at line 159 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetAckermannControllerSettings()
| rpc::AckermannControllerSettings carla::client::Vehicle::GetAckermannControllerSettings | ( | ) | const |
Return the last Ackermann controller settings applied to this vehicle.
- Warning
- This function does call the simulator.
Definition at line 62 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetControl()
| Vehicle::Control carla::client::Vehicle::GetControl | ( | ) | const |
Return the control last applied to this vehicle.
- Note
- This function does not call the simulator, it returns the data received in the last tick.
Definition at line 114 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
Referenced by carla::rss::RssCheck::GetSteeringAngle().
◆ GetFailureState()
| rpc::VehicleFailureState carla::client::Vehicle::GetFailureState | ( | ) | const |
Returns the failure state of the vehicle.
Definition at line 175 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetLightState()
| Vehicle::LightState carla::client::Vehicle::GetLightState | ( | ) | const |
Return the current open lights (LightState) of this vehicle.
- Note
- This function does not call the simulator, it returns the data received in the last tick.
Definition at line 126 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetPhysicsControl()
| Vehicle::PhysicsControl carla::client::Vehicle::GetPhysicsControl | ( | ) | const |
Return the physics control last applied to this vehicle.
- Warning
- This function does call the simulator.
Definition at line 118 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetSpeedLimit()
| float carla::client::Vehicle::GetSpeedLimit | ( | ) | const |
Return the speed limit currently affecting this vehicle.
- Note
- This function does not call the simulator, it returns the data received in the last tick.
Definition at line 134 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetTelemetryData()
| Vehicle::TelemetryData carla::client::Vehicle::GetTelemetryData | ( | ) | const |
Return the runtime telemetry of this vehicle: forward speed, last applied control inputs, engine RPM, current gear, and per-wheel lateral slip, longitudinal slip, and angular velocity sourced from the Chaos vehicle physics state.
- Warning
- This function does call the simulator.
Definition at line 122 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetTrafficLight()
| SharedPtr< TrafficLight > carla::client::Vehicle::GetTrafficLight | ( | ) | const |
Retrieve the traffic light actor currently affecting this vehicle.
Definition at line 146 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), carla::client::detail::ActorState::GetWorld(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetTrafficLightState()
| rpc::TrafficLightState carla::client::Vehicle::GetTrafficLightState | ( | ) | const |
Return the state of the traffic light currently affecting this vehicle.
- Returns
- Green If no traffic light is affecting the vehicle.
- Note
- This function does not call the simulator, it returns the data received in the last tick.
Definition at line 138 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetVehicleBoneWorldTransforms()
| std::vector< geom::Transform > carla::client::Vehicle::GetVehicleBoneWorldTransforms | ( | ) | const |
Definition at line 130 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetWheelPitchAngle()
| float carla::client::Vehicle::GetWheelPitchAngle | ( | WheelLocation | wheel_location | ) |
Return the spin angle of a wheel, in degrees.
Definition at line 98 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetWheelSteerAngle()
| float carla::client::Vehicle::GetWheelSteerAngle | ( | WheelLocation | wheel_location | ) |
Return a Rotation from a wheel of the vehicle.
- Note
- The function returns the rotation of the vehicle based on the it's physics
Definition at line 90 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ GetWheelSuspensionOffset()
| float carla::client::Vehicle::GetWheelSuspensionOffset | ( | WheelLocation | wheel_location | ) |
Return the suspension compression of a wheel, in meters.
Definition at line 106 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ IsAtTrafficLight()
| bool carla::client::Vehicle::IsAtTrafficLight | ( | ) |
Return whether a traffic light is affecting this vehicle.
- Note
- This function does not call the simulator, it returns the data received in the last tick.
Definition at line 142 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ OpenDoor()
| void carla::client::Vehicle::OpenDoor | ( | const VehicleDoor | door_idx | ) |
Open a door in this vehicle.
Definition at line 74 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ SetAutopilot()
| void carla::client::Vehicle::SetAutopilot | ( | bool | enabled = true, |
| uint16_t | tm_port = TM_DEFAULT_PORT |
||
| ) |
Switch on/off this vehicle's autopilot.
Definition at line 38 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), carla::traffic_manager::TrafficManager::RegisterVehicles(), and carla::traffic_manager::TrafficManager::UnregisterVehicles().
◆ SetLightState()
| void carla::client::Vehicle::SetLightState | ( | const LightState & | light_state | ) |
Sets a LightState to this vehicle.
Definition at line 82 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ SetWheelAnimationOverride()
| void carla::client::Vehicle::SetWheelAnimationOverride | ( | bool | enabled | ) |
Enables or disables the wheel animation override, in which the wheels show only the values set through the wheel setters (affects the bones of the car skeleton, not the physics)
Definition at line 110 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ SetWheelPitchAngle()
| void carla::client::Vehicle::SetWheelPitchAngle | ( | WheelLocation | wheel_location, |
| float | angle_in_deg | ||
| ) |
Sets the spin angle of a wheel, in degrees (affects the bone of the car skeleton, not the physics)
Definition at line 94 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ SetWheelSteerDirection()
| void carla::client::Vehicle::SetWheelSteerDirection | ( | WheelLocation | wheel_location, |
| float | angle_in_deg | ||
| ) |
Sets a Rotation to a wheel of the vehicle (affects the bone of the car skeleton, not the physics)
Definition at line 86 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ SetWheelSuspensionOffset()
| void carla::client::Vehicle::SetWheelSuspensionOffset | ( | WheelLocation | wheel_location, |
| float | offset | ||
| ) |
Sets the suspension compression of a wheel, in meters (affects the bone of the car skeleton, not the physics)
Definition at line 102 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ ShowDebugTelemetry()
| void carla::client::Vehicle::ShowDebugTelemetry | ( | bool | enabled = true | ) |
Switch on/off this vehicle's autopilot.
Definition at line 47 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
◆ UseCarSimRoad()
| void carla::client::Vehicle::UseCarSimRoad | ( | bool | enabled | ) |
Enables the use of CarSim internal road definition instead of unreal's.
Definition at line 155 of file Vehicle.cpp.
References carla::client::detail::ActorState::GetEpisode(), and carla::client::detail::EpisodeProxyImpl< PointerT >::Lock().
Member Data Documentation
◆ _control
|
private |
Definition at line 176 of file Vehicle.h.
Referenced by ApplyControl().
◆ _is_control_sticky
|
private |
Definition at line 174 of file Vehicle.h.
Referenced by ApplyControl().
The documentation for this class was generated from the following files:
